30초 요약
Matthew Berman uses Boston Dynamics’ Atlas as an example of a humanoid robot designed with movement beyond human limits. He argues that faster repositioning and heavy lifting could be valuable in factories, while describing these benefits as potential applications.
- 1Beyond human movementBerman points to rotating hands, legs and torso as examples of mobility that differs from human anatomy.
- 2Factory efficiencyHe argues that faster repositioning could save time during repetitive industrial work.
- 3Future deploymentBerman expects heavy lifting and humanoid mobility to change factory work.
핵심 정리
- A humanoid robot need not copy every limitation of human anatomy.
- Rotating joints can give a robot more options for repositioning.
- Berman expects these capabilities to matter in industrial work.
챕터별로 다듬은 전문 읽기
Designing beyond human anatomy
Berman describes humanoid robots with joints that can rotate beyond normal human ranges. He discusses why those capabilities could matter in factories.
The human hand is remarkable, but a robot does not have to inherit every limitation of human anatomy. Boston Dynamics takes a humanoid form and gives it capabilities such as hands that can rotate fully, legs that move in unfamiliar directions and a torso that can turn around.
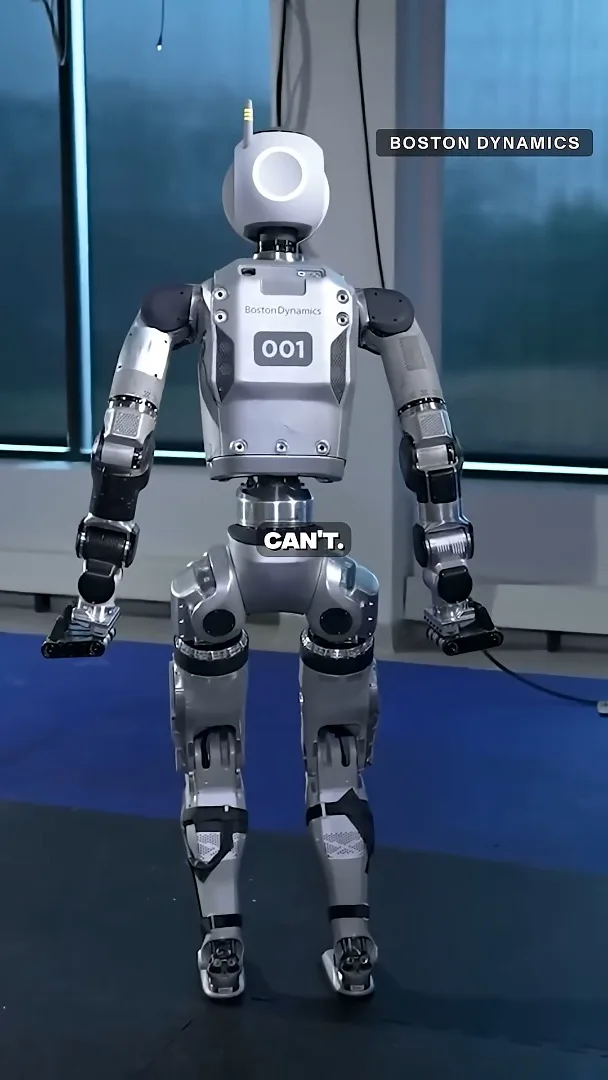
I think that flexibility could matter in a factory, where repeated movements add up. If a robot can reposition more quickly than a person, it could save time during a task. The benefit depends on the actual operation and the robot’s performance in that environment.
Boston Dynamics has a long history of robotics demonstrations, from its four-legged machines to Atlas. I expect newer humanoid robots capable of moving heavy objects to change factory work as they are deployed. How would it feel to work alongside one?
같은 채널의 다른 글
 25:50EN
 32:20EN
 45:08EN
 0:32EN
 12:14EN
 10:36EN