En 30 secondes
3Blue1Brown uses a damped spring driven by a periodic force to show how the Laplace transform converts differentiation into algebra and how poles expose the resulting motion. The lesson ends with two approaches to the derivative rule and a preview of the inverse transform.
- 1Poles describe dynamicsComplex pole locations reveal oscillation, decay or growth in exponential components.
- 2Differentiation becomes algebraThe Laplace transform of f′ is sF(s)−f(0), explicitly retaining the initial condition.
- 3Separate transient and steady motionThe forcing and the oscillator contribute different poles; damping makes the natural component fade.
- 4Invert with partial fractionsDistinct simple poles can be decomposed into terms whose inverse transforms are exponentials.
- 5Where the derivative rule comes fromIntegration by parts derives the rule directly from the transform integral.
À retenir
- The transform maps an exponential e^(at) to 1/(s−a), so poles can reveal exponential components.
- The derivative rule incorporates initial position and velocity as it turns a differential equation into algebra.
- For a damped oscillator, transient natural motion decays while the periodic forcing leaves a steady oscillation.
- Partial fractions recover time-domain exponentials when the transformed expression has suitable distinct poles.
- Integration by parts establishes the derivative rule under the usual convergence conditions.
Lire le texte remanié, chapitre par chapitre
A spring with an external force
A driven spring initially behaves irregularly before settling into a rhythm. The Laplace transform gives a way to understand both phases.
Imagine a mass on a spring, pushed by an external force that oscillates at a frequency unrelated to the spring’s natural frequency. The motion initially grows and shrinks irregularly, then settles into a rhythm. Can we predict the startup motion, how long it lasts and the size of the eventual swings?
Exponential pieces and poles
The s-plane describes growth and oscillation in exponentials. Poles in the transformed function expose those components.
The previous chapters introduced the complex s-plane. Each point s represents an exponential e^(st): the imaginary part governs oscillation, while the real part determines growth or decay. Many physical motions can be understood by breaking them into such exponential pieces.
A Laplace transform turns a function of time into a function of the complex variable s. In the kinds of examples considered here, poles of the transformed function reveal exponential pieces of the original. Specifically, e^(at) transforms to 1/(s−a), where the defining integral converges for Re(s) > Re(a).
The transform is linear: transforming a weighted sum gives the same weighted sum of transforms. Thus a sum of exponentials becomes a sum of fractions, with poles corresponding to the constituent exponentials. Imaginary parts suggest oscillation; negative real parts indicate decay, while positive real parts signal growth.
In physics we often know a differential equation without knowing its solution. The transform can take us directly from that equation to a transformed solution, which is valuable both as a step toward a formula and as a representation of the system’s dynamics.
Turning derivatives into algebra
The derivative rule introduces initial conditions. It makes the differential equation of a driven oscillator an algebra problem.
The crucial third rule is ℒ{f′}(s) = sF(s) − f(0). Differentiation in time becomes multiplication by s, with a correction for the initial value. That correction may seem untidy, but it automatically carries an initial condition into the algebra.
Consider a spring whose restoring force is −kx and whose damping force is proportional to velocity. Add a periodic external force F₀ cos(ωt), like wind blowing alternately in opposite directions. The frequency ω need not equal the spring’s own frequency.
The resulting equation is m x″ + μx′ + kx = F₀ cos(ωt). It is still linear, but it is now driven: the right-hand side is nonzero. Similar mathematics appears in the channel’s discussion of light driving charges in a material.
Write X(s) for the transform of x(t), x₀ for its initial position and v₀ for its initial velocity. The derivative rule gives ℒ{x′} = sX − x₀. Applying it again gives ℒ{x″} = s²X − sx₀ − v₀, so both initial conditions enter the transformed equation.
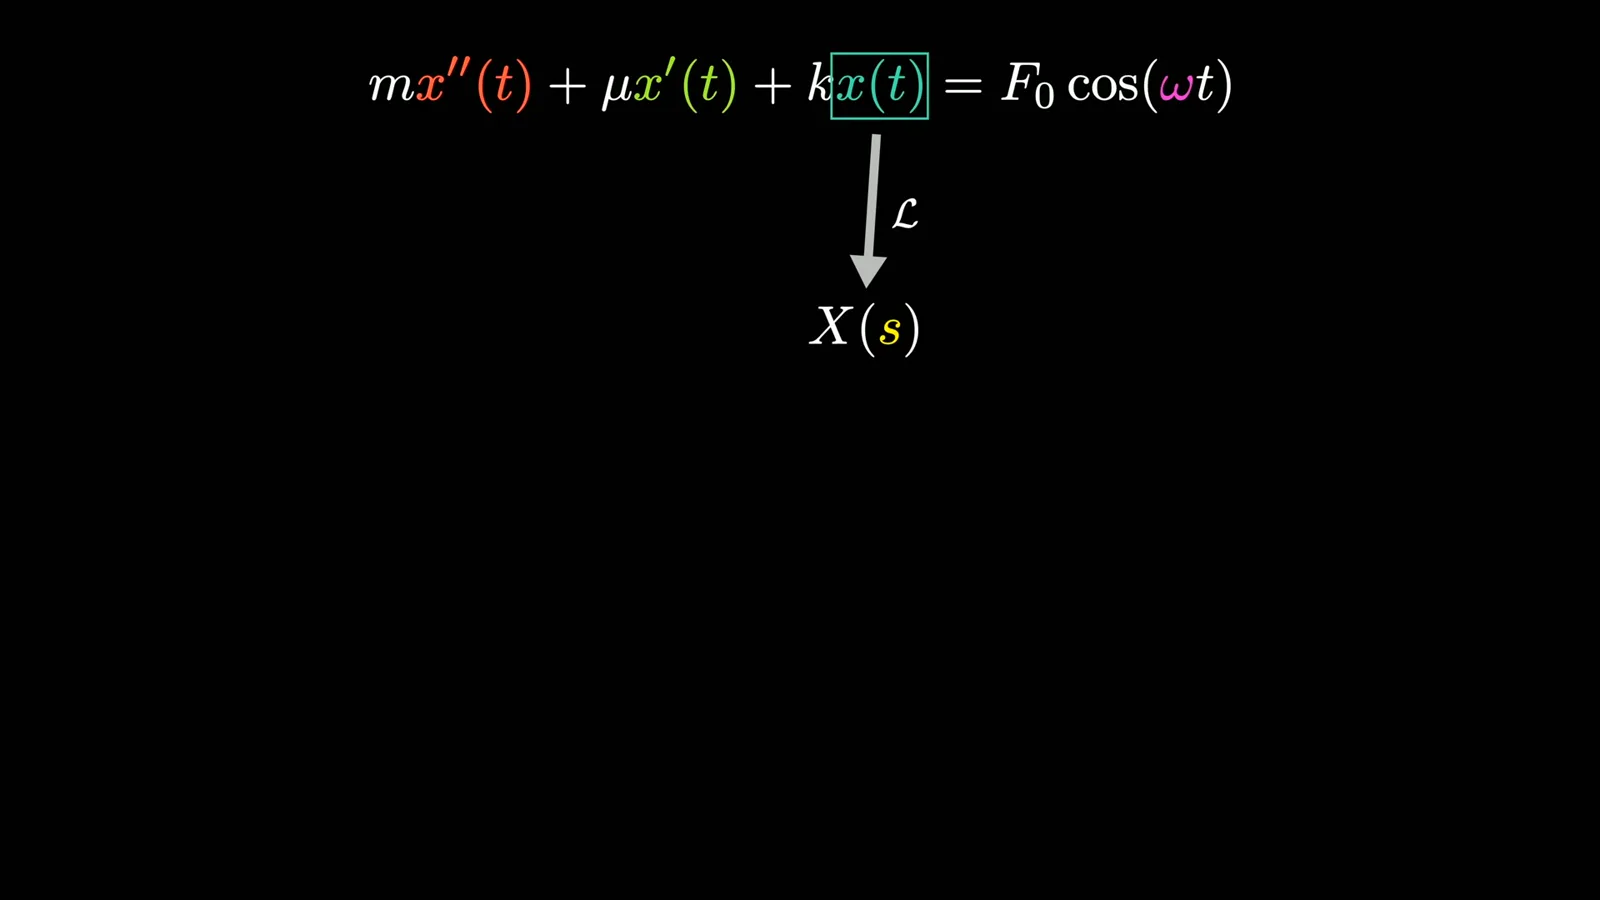
The terms multiplying X combine into the polynomial ms² + μs + k. For a cleaner first example, suppose x₀ = v₀ = 0. The derivatives have now become powers of s, leaving an equation that can be manipulated algebraically.
The transform of cos(ωt) is s/(s² + ω²). The denominator has roots at ±iω, reflecting the forcing’s oscillation. Dividing by the oscillator polynomial gives X(s) = F₀s/[(s² + ω²)(ms² + μs + k)] for the zero-initial-condition example.
Reading the poles
Natural poles describe a damped transient, while the forcing poles describe the sustained oscillation. The simulation shows the two components together.
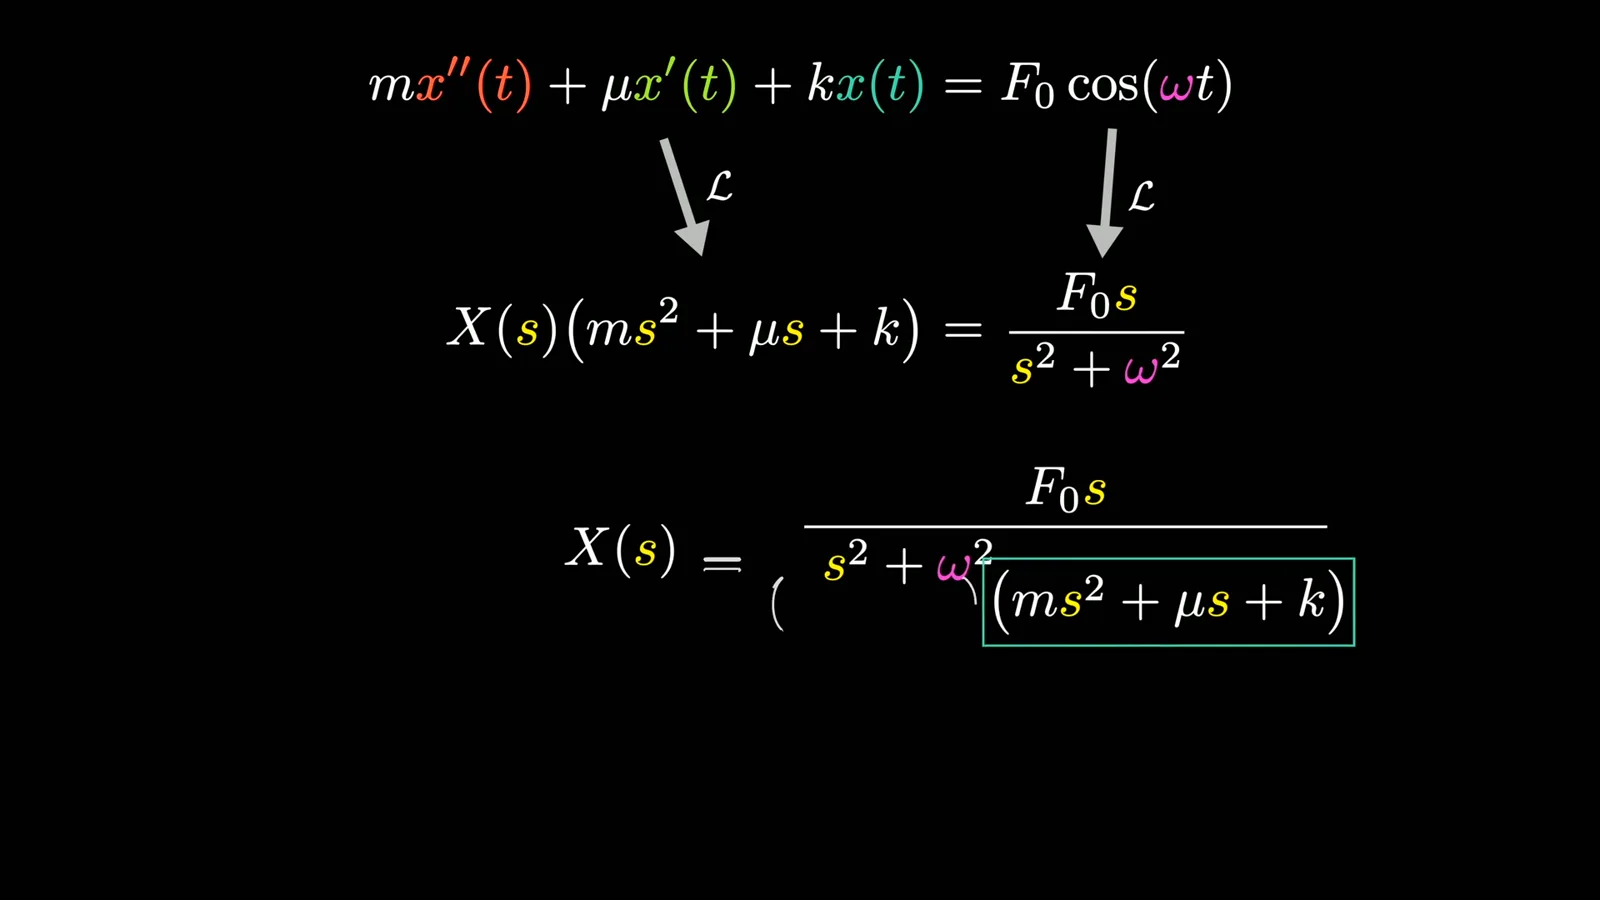
Before inverting X, inspect its poles. The roots of ms² + μs + k represent the natural motion; for positive mass, stiffness and damping they have negative real parts. When damping is small enough for the underdamped case, they also have imaginary parts, indicating oscillation that fades.
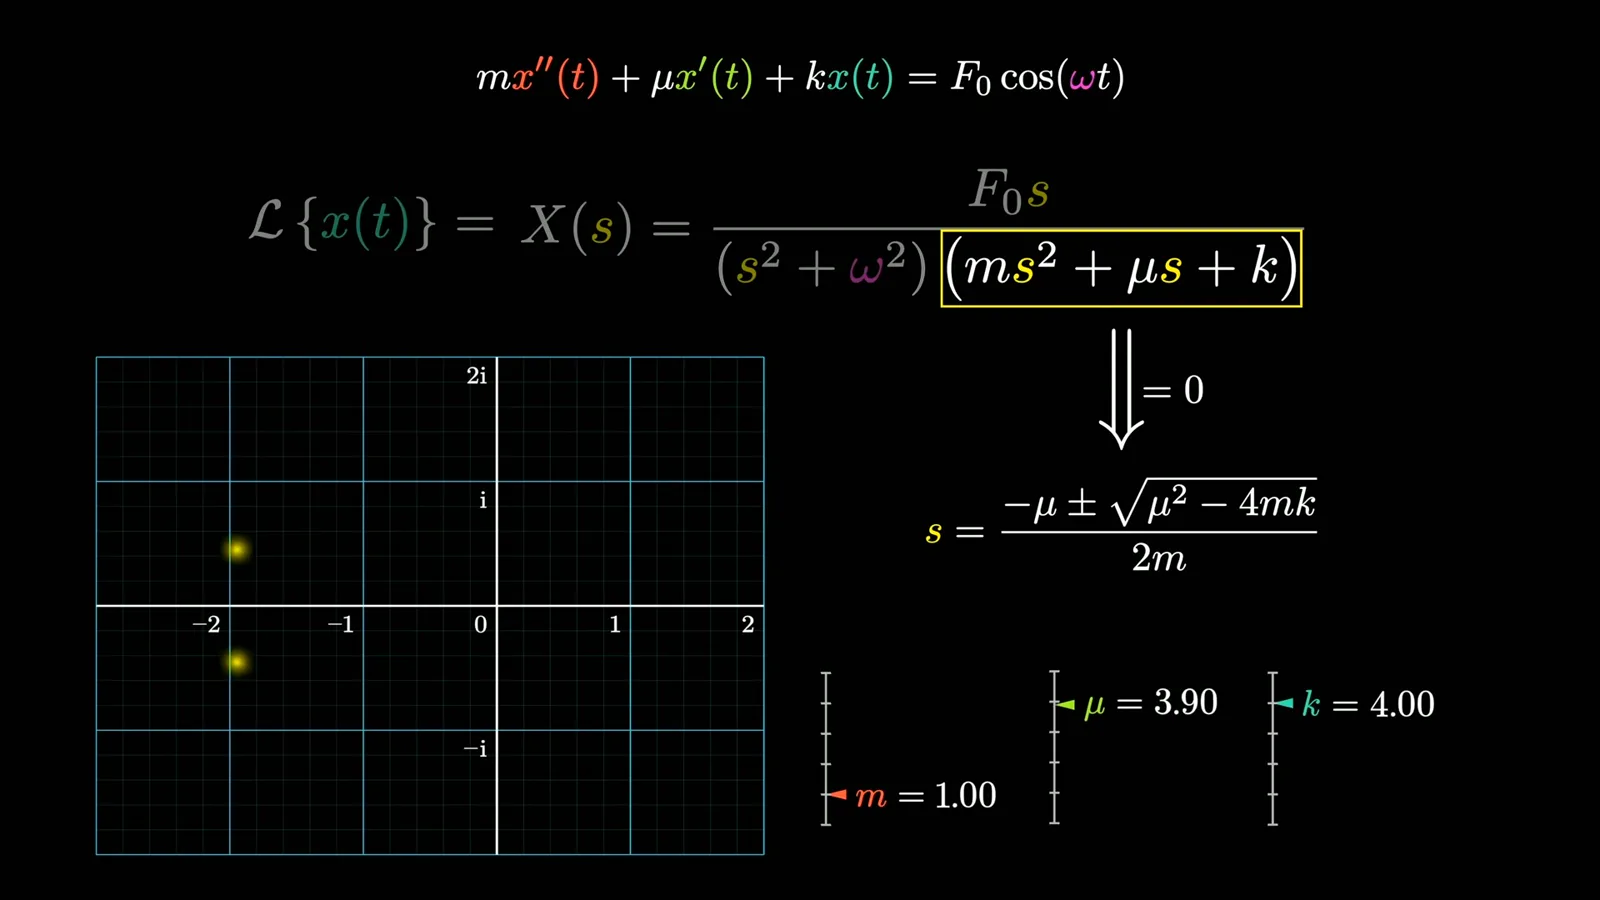
The other two poles, at ±iω, come from the driving force and describe sustained oscillation at its frequency. Think of pushing a swing at a frequency different from its natural one: once transients die away, the enduring response follows the forcing frequency.
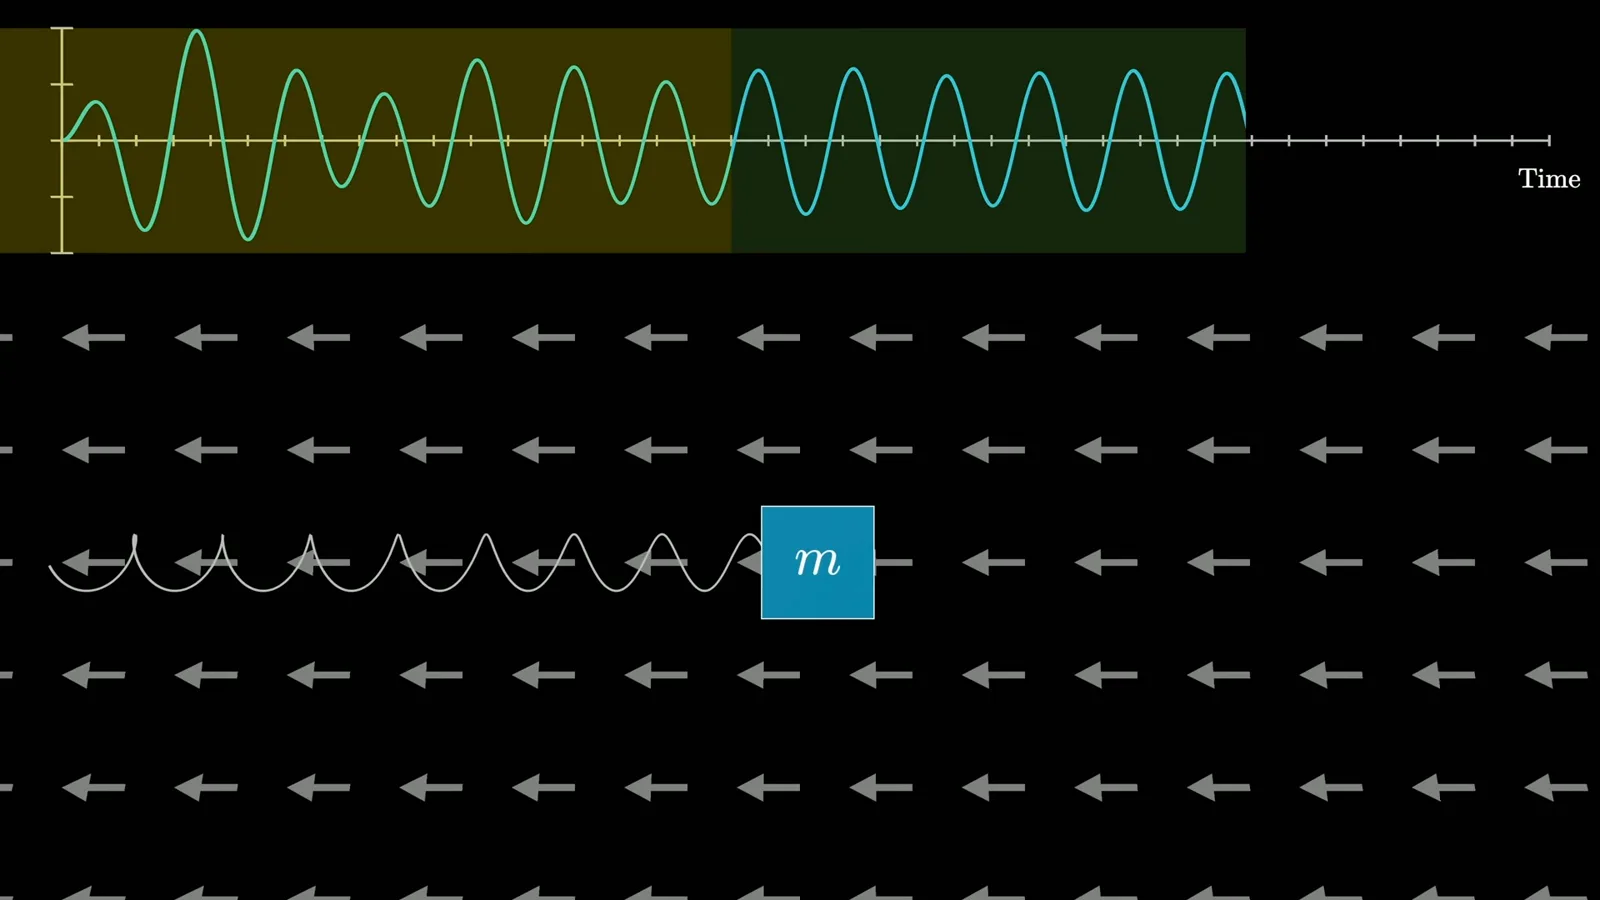
The simulation makes the distinction visible. The irregular startup is the sum of a decaying natural component and the continuing forced component. As the former fades, the latter remains as a steady sinusoid, generally with a phase shift relative to the force.
Recovering a solution
Partial fractions turn the transformed expression into exponential terms. Their coefficients determine the steady-state amplitude.
To find an explicit expression, use partial fraction decomposition. When the four poles are distinct and uncancelled, X can be written as a sum of terms with denominators s minus a pole. Each term inverts to an exponential whose exponent is that pole, multiplied by its coefficient. Repeated poles require a modified decomposition.
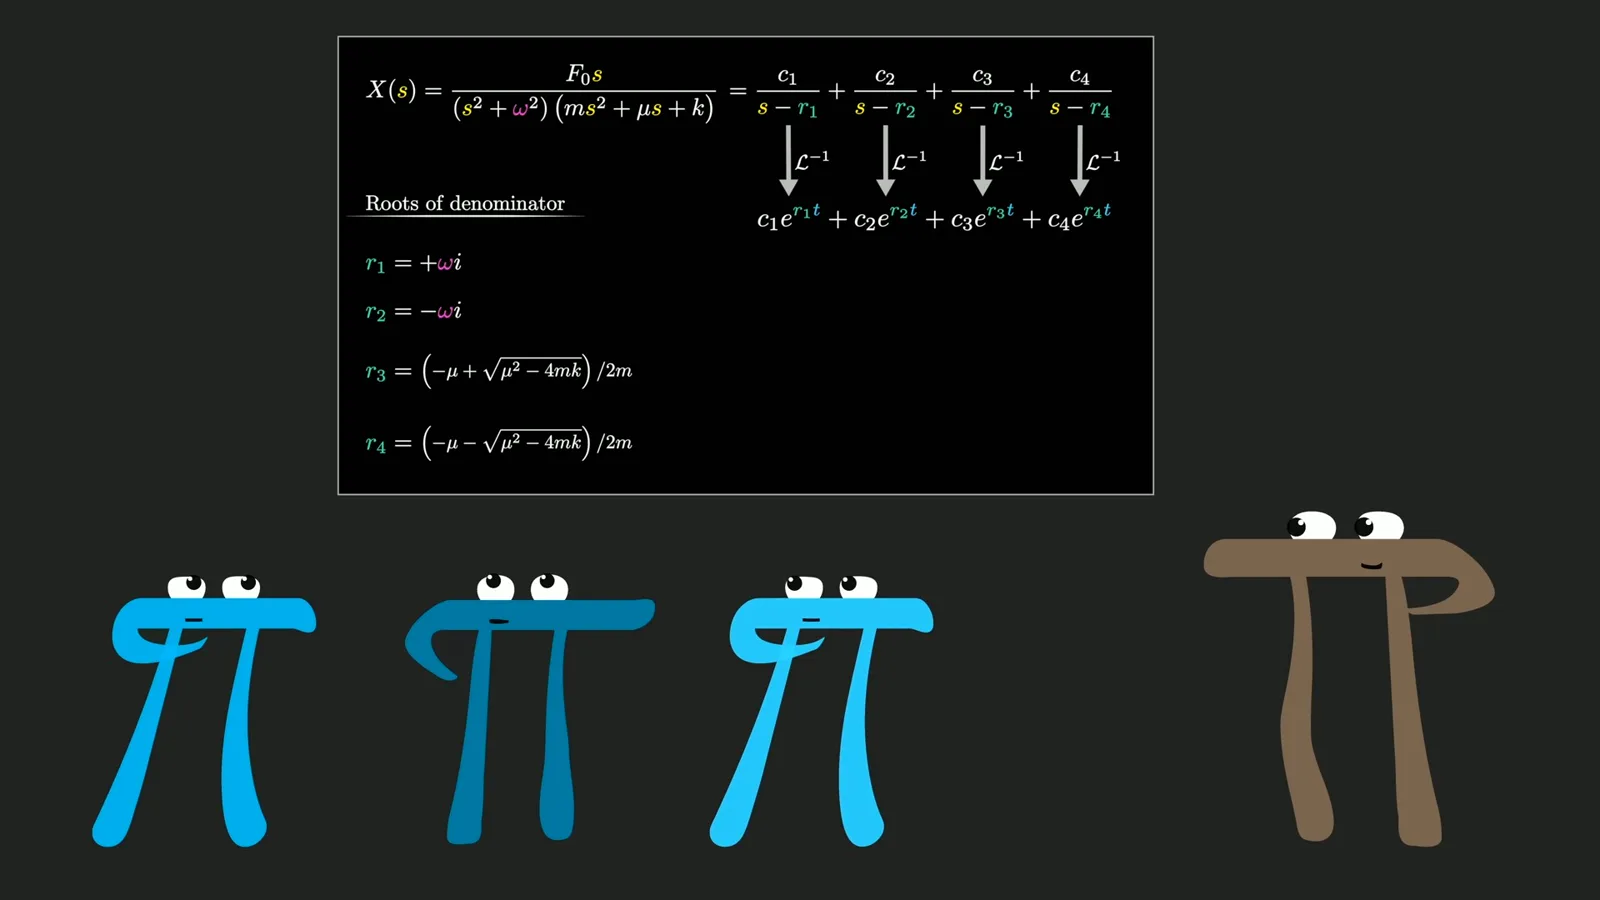
The coefficients of the two forcing terms combine into the steady oscillation. In the small-damping approximation shown in the video, their form invites an examination of how response amplitude changes as the driving frequency approaches the spring’s resonant frequency. Damping matters when analyzing the response near resonance.
This is the broad strategy: transform the differential equation, solve the resulting algebraic equation, inspect the poles and invert if an explicit time-domain answer is needed. The whole procedure depends on the derivative rule.
Why the derivative rule works
An exponential example and integration by parts illuminate the rule. A future chapter will develop inversion more generally.
First test that rule on f(t) = e^(at). Its derivative is ae^(at), so linearity gives a/(s−a). A small algebraic rearrangement gives s/(s−a) − 1, exactly sF(s) − f(0), since f(0) = 1.
Linearity extends this check to finite combinations of exponentials. That is useful intuition, though it is not a general proof. The familiar textbook proof starts from the defining Laplace integral and applies integration by parts, under conditions that make the boundary term at infinity vanish.
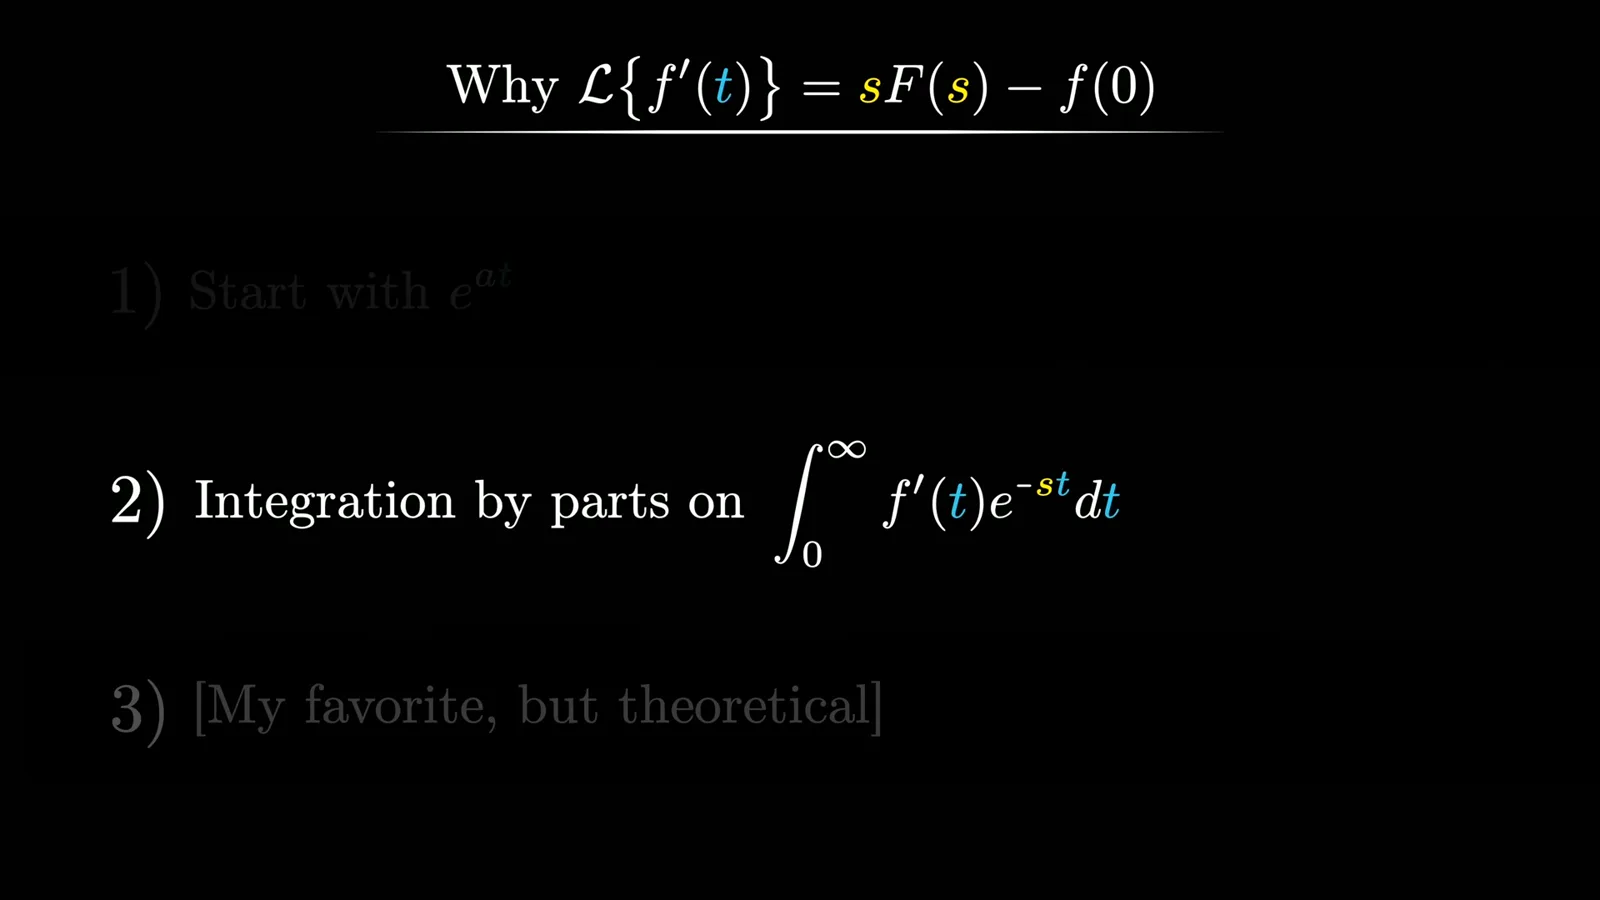
Integration by parts is concise, but the speaker finds it less illuminating about why multiplication by s and the initial condition fit the transform’s purpose. A third explanation relies on the inverse Laplace transform, which has not yet been developed.
The inverse matters beyond cases that break neatly into simple fractions: what if the original function is not a discrete sum of exponentials? The next chapter will explore inversion, contour integrals and the relationship with Fourier transforms, building the transform and its inverse together.
Sur la même chaîne
 40:44EN
 3Blue1Brown· 16 oct. 2026Grant Sanderson: There's never been a better time to go into mathGrant Sanderson, Constantin Kogler · 3Blue1BrownStudents fear AI has solved mathematics. Grant Sanderson argues the opposite: even if machines prove theorems better than we do, the institution of math stays valuable—and this is a rare moment when newcomers can reshape it.
 51:55EN3Blue1Brown· 18 sept. 2026The last IMO problem AI could not solveGrant Sanderson · 3Blue1BrownGrant Sanderson walks through IMO 2025 Problem 6 — a tiling puzzle that frontier models missed — and the visual patience it takes to prove a construction is optimal.
 0:55EN3Blue1Brown· 24 juil. 2026The 64 Sugar Cubes Puzzle: Six Equal DistancesA 4×4×4 block has three colors; prove that six same-colored pairs share a distance.
 2:25EN3Blue1Brown· 12 juin 2026How Shannon Measured the Entropy of EnglishA guessing game helped Claude Shannon estimate how much information English text contains, and why prediction is central to compression.
 1:02EN3Blue1Brown· 10 juin 2026A Robot Walk and the Puzzle of Optimal Binary EncodingHow few bits does it take to send directions that occur with unequal frequencies?
 32:19EN3Blue1Brown· 7 juin 2026Reinventing Entropy: Why Prediction Helps Compress LanguageA robot’s movement code leads from prefix-free encoding to Shannon information and the entropy of language.