30초 요약
Matthew Berman shares footage of 1X’s EVE robots and repeats the company’s claim that the demonstrated behaviors use vision-based neural control without live teleoperation or scripted replay. He expresses enthusiasm for future household robots. In its original description, 1X says the behaviors were trained using human demonstration data and task-specific fine-tuning; the clip does not establish general intelligence or household readiness.
- 1A 1X robot demonstrationBerman introduces footage from the robotics company 1X, which he describes as backed by OpenAI.
- 2Vision-based controlHe repeats the claim that behaviors are generated from visual input without live human control or scripted replay in the demo.
- 3Hopes for home robotsBerman says he looks forward to a robot that can help with everyday chores.
핵심 정리
- 1X says its February 2024 EVE demonstration uses vision-based neural control for robot actions without live teleoperation in the demonstrated footage.
- The company describes a base model trained on human demonstrations and further fine-tuning for specific capabilities and tasks.
- Autonomous execution in a selected demo does not establish autonomous performance in every environment.
- Berman is optimistic about household assistance, but the clip does not establish when robots can reliably perform everyday chores.
챕터별로 다듬은 전문 읽기
The robot demonstration
Berman introduces footage from 1X and describes the company’s neural-control claims. The company’s original account also describes training and task-specific fine-tuning.
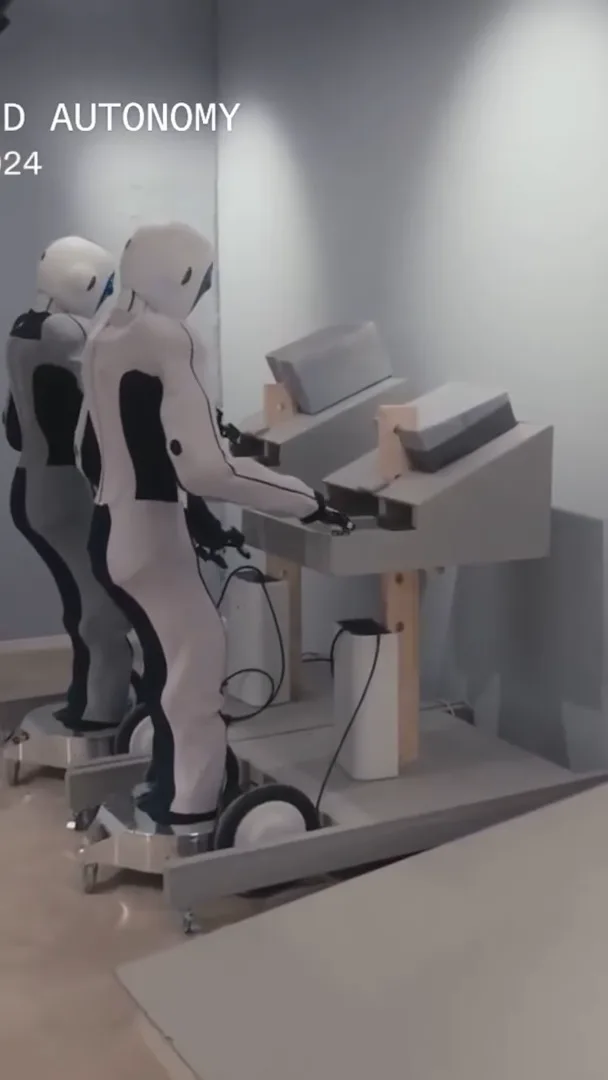
1X, a robotics company backed by OpenAI, has shared a demonstration of its humanoid EVE robots. I find the footage impressive. The company’s [February 2024 description](https://1x-tech.webflow.io/discover/all-neural-networks-all-autonomous-all-1x-speed) says its vision-based network takes images and produces actions controlling the robot’s mobility, arms, gripper, torso, and head.
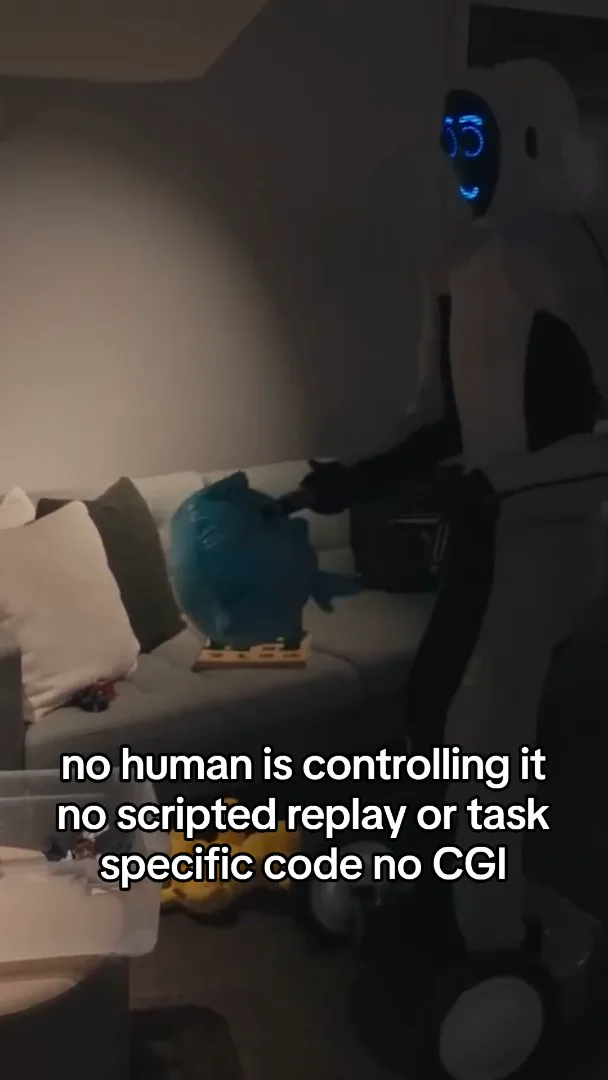
I describe the demonstrated behavior as going from pixels to actions without a human remotely controlling the robot, scripted replay, task-specific code, or CGI. Those are claims about the demonstration, not independent proof of general intelligence. 1X also says it trained a base model on human demonstrations and fine-tuned models for specific capabilities and tasks; autonomous execution in the footage does not mean human demonstrations were absent from training.
A hope for household help
Berman expresses excitement about future robots helping around the house. The demonstration does not establish when that will be reliable.
I am waiting for the day when a humanoid robot can help with everyday chores in my home. Some people are concerned about that future, but I am excited by the prospect. A selected demonstration alone does not establish reliability in unfamiliar homes or a timetable for routine household use.
같은 채널의 다른 글
 34:21EN
 Matthew Berman· 2026년 10월 27일Matthew Berman Examines Anthropic’s IPO Filing, AI Growth and GovernanceMatthew Berman, Sam Altman · Forward FutureThe presenter reviews the S-1’s financial metrics, compute strategy and voting structure while questioning the tension between rapid AI development and safety.
 0:26ENMatthew Berman· 2026년 10월 25일Sam Altman on Human Values and Problem-Solving in an AI WorldSam Altman · OpenAIIn a short interview excerpt, Altman considers the enjoyment of solving hard problems and the human role in interpreting results.
 0:36ENMatthew Berman· 2026년 10월 25일Kimi K3.1 and a Rubik’s Cube Solver DemonstrationMatthew Berman · Forward FutureMatthew Berman shows a scrambled virtual cube being solved and gives the Kimi K3.1 test a favorable assessment.
 0:21ENMatthew Berman· 2026년 10월 24일An AI-Generated Kimi Benchmark Chart Used Invented ScoresMatthew Berman · Forward FutureMatthew Berman asks for a graph of Kimi K3.1 Pro benchmarks, then discovers that the displayed figures are illustrative placeholders.
 25:50ENMatthew Berman· 2026년 10월 24일Kimi K3.1 Pro Tested: Strong 3D Demos, Uneven Results and Competitive PricingMatthew Berman · Forward FutureMatthew Berman tests the open-weight model on coding, 3D rendering and visual explanations, then compares benchmark results and prices.
 32:20ENMatthew Berman· 2026년 10월 23일Who Is Local AI For? The Costs, Trade-offs and a Hybrid FutureMatthew Berman · Forward FutureMatthew Berman weighs data control and independence against hardware cost, setup complexity and inference speed.