30 秒でわかる
Matthew Berman reacts to a series of robotics videos, led by Astribot's household manipulation demonstration. He also discusses DeepMind's soccer research, Booster and Unitree mobility, household research prototypes, Ringbot and Sanctuary AI. His forecast of widespread household robots is a prediction; selected clips and maker claims do not establish general-purpose reliability.
- 1Astribot's manipulation demoBerman highlights cup stacking, sorting and delicate food preparation. The video's speed and autonomy labels are claims by the demonstration maker.
- 2Why simple tasks are hardHe contrasts precise, flexible manipulation with moving a fixed heavy object.
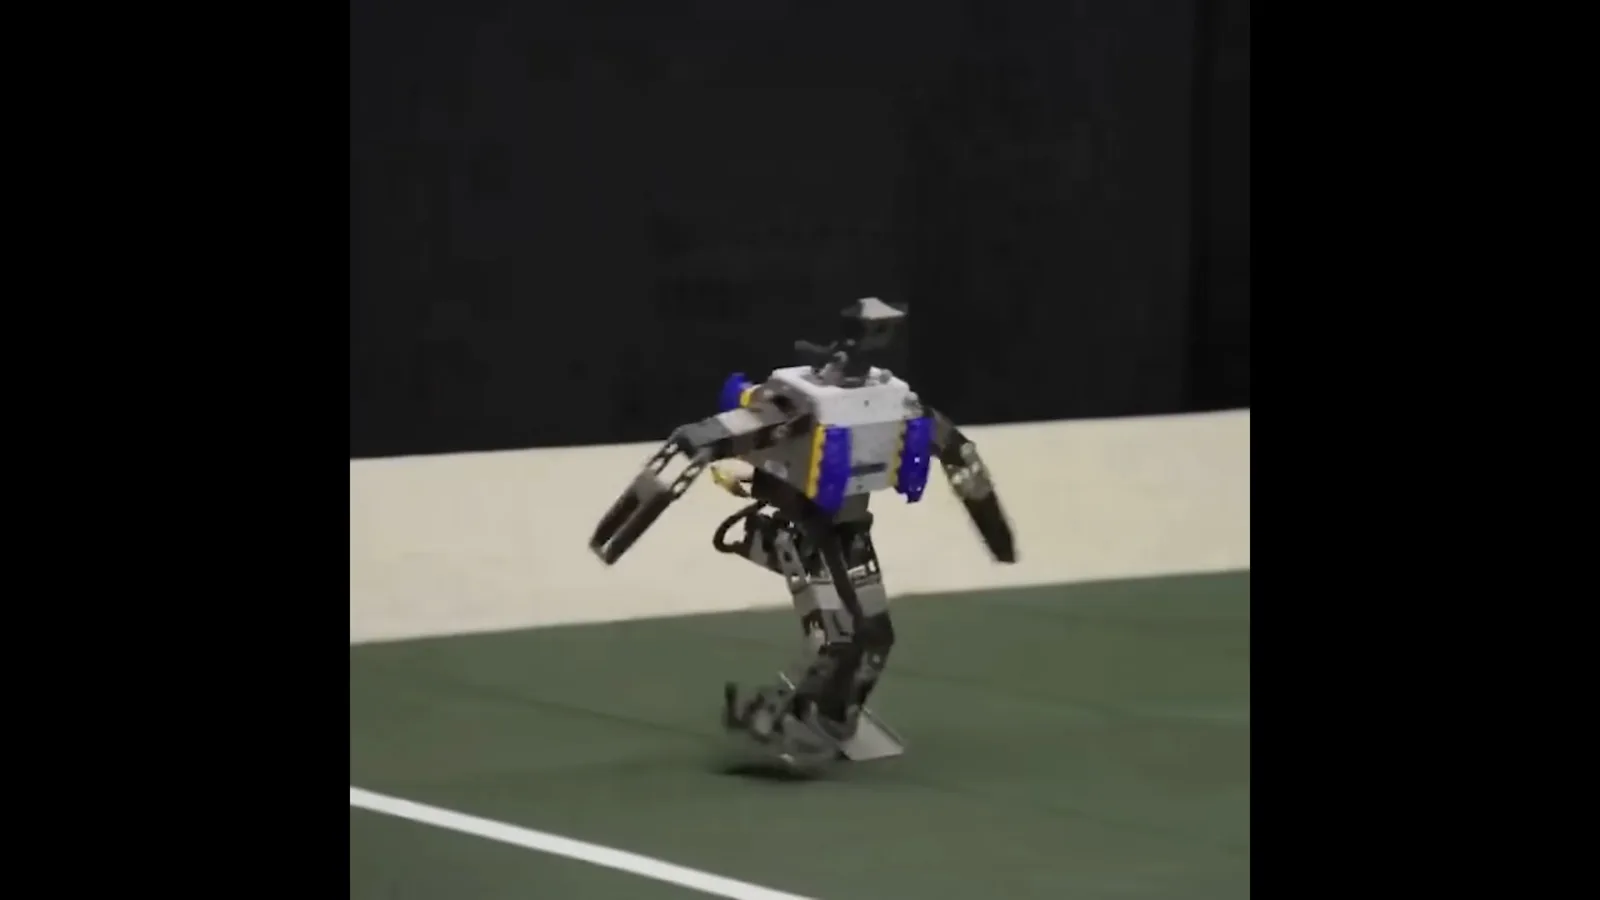
- 3Bipedal soccerDeepMind's robots kick, move and recover in a simplified one-on-one game.
- 4Sponsored segmentBright Data sponsors a discussion of web scraping and datasets.
- 5A legged monocycleRingbot combines a wheel and legs to traverse different terrain.
ポイント
- Astribot's demonstration shows manipulation tasks and labels the footage as normal speed without teleoperation; its general reliability is not established by the clip.
- Robotic manipulation of flexible or delicate objects can be difficult even when a task is simple for a human.
- DeepMind's bipedal soccer research studied a simplified one-on-one game using reinforcement learning.
- Other videos show mobility and manipulation research, but individual demonstrations do not prove broad readiness for household deployment.
- Berman's video includes a sponsored Bright Data segment.
チャプターごとに整えた全文を読む
Astribot's household demonstration
Berman watches a manipulation reel and discusses the precision shown. Claims about autonomy and household readiness require more evidence than the footage alone.
A new Astribot demonstration from China shows a robot handling a range of household tasks. I find its dexterity impressive and expect robots like this to enter homes soon, though the video does not establish a rollout timetable or reliable performance in ordinary homes.
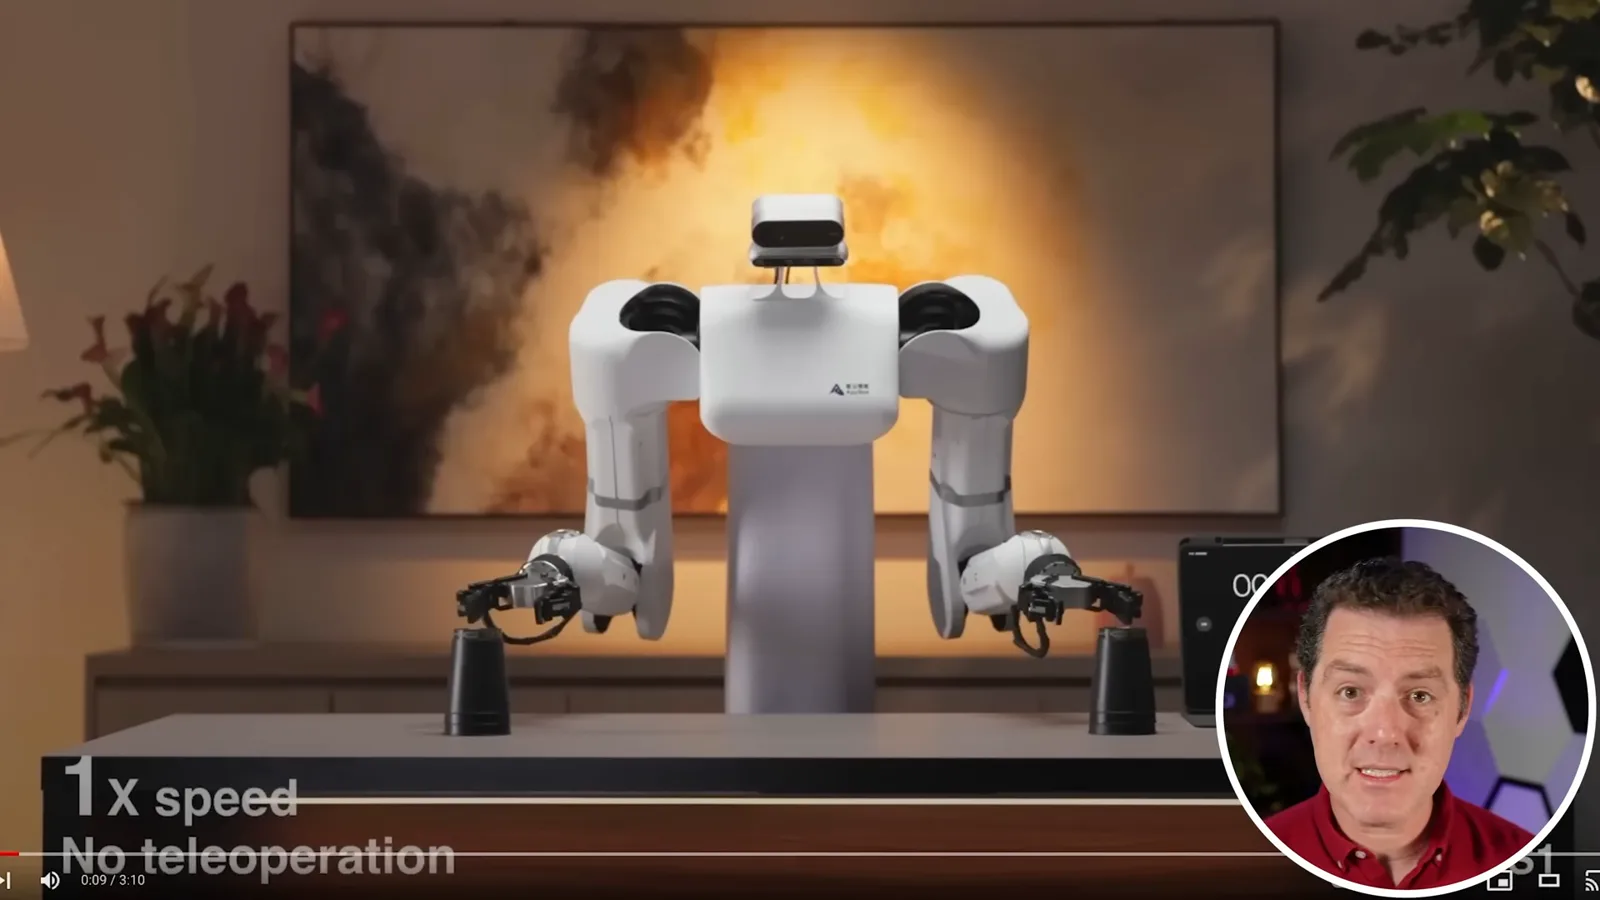
I replay the demonstration and note the fast cup stacking and the tablecloth pulled out from under glasses. The video labels the footage as normal speed and says there is no teleoperation; those are the demo maker's claims, not independently established performance statistics.
In another example the robot identifies objects on a table and sorts them. I think the display may involve a language model, but I am unsure what the numbers on screen mean. The clip alone does not establish the full control system or how much preparation was required.
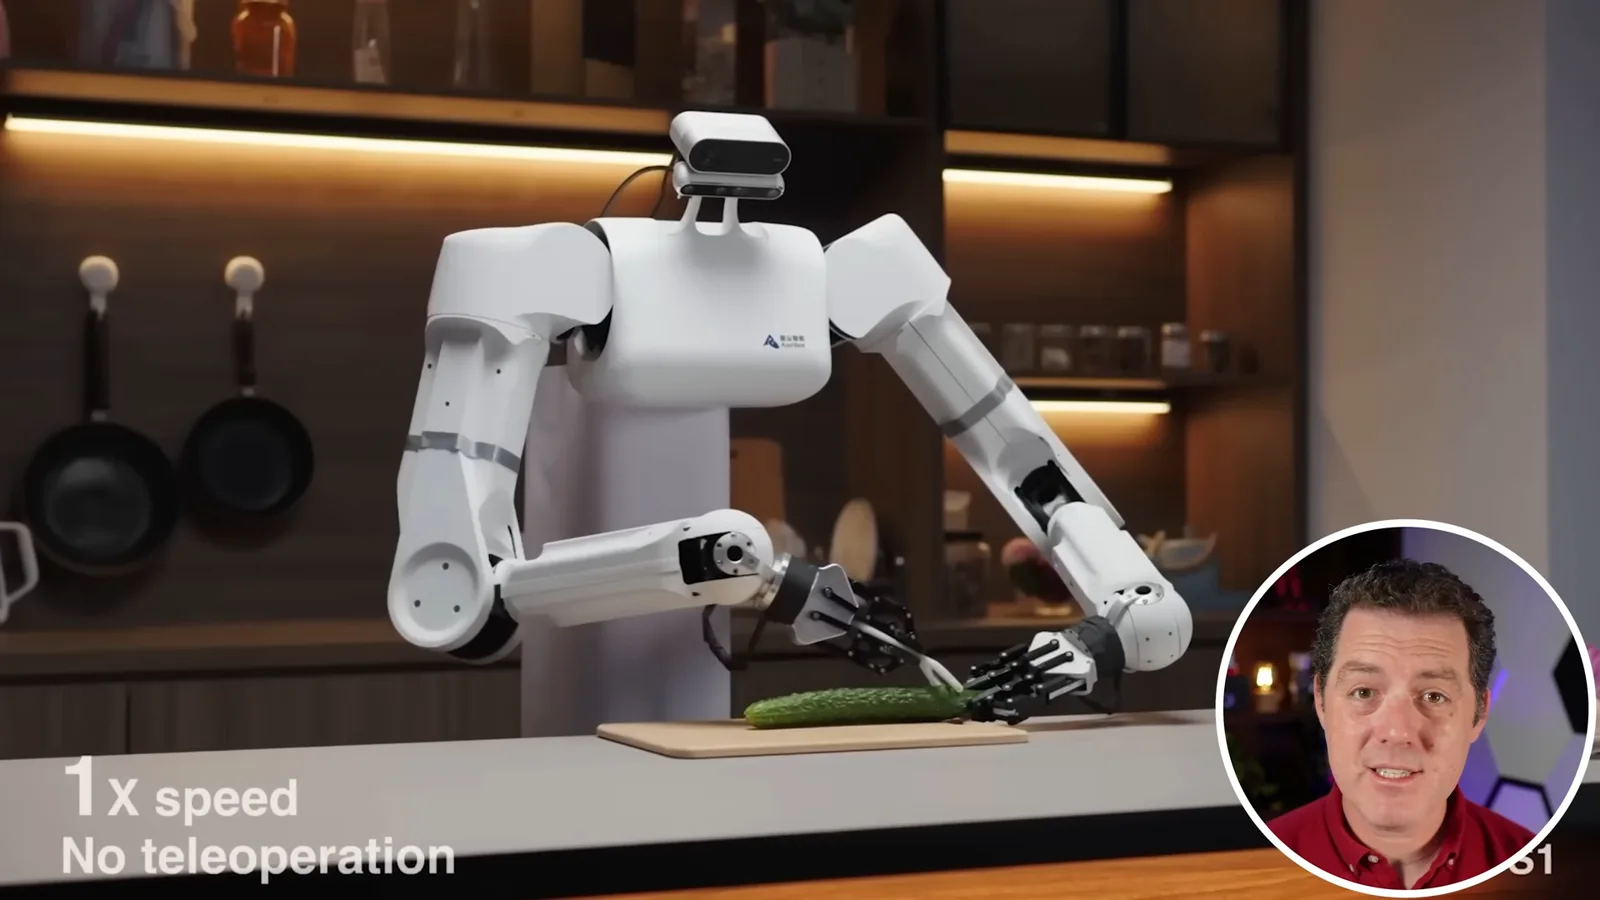
The robot handles small objects, closes a drawer and peels a cucumber. It also prepares vegetables and flips bread in a pan. These selected demonstrations illustrate dexterity under the shown conditions; they don't establish how often the robot succeeds across varied objects and settings.
Tasks that people find simple can be surprisingly hard to automate. I recall Elon Musk describing excessive automation at Tesla and difficulties with small assembly tasks. Handling a heavy object in a fixed position can be easier to engineer than manipulating a flexible or delicate object in an uncontrolled environment.
I am struck by the combination of force and gentleness in folding, hammering and plugging in a cable. The video also shows learning from human examples and different end effectors. I interpret the footage as autonomous, but the training and evaluation details cannot be inferred solely from the video.
Soccer and standing robots
He looks at DeepMind soccer research and a Booster Robotics standing demonstration.
Next I show Google DeepMind's small bipedal robots playing soccer. They move on two legs, kick a ball and recover after falls. The research studied a simplified one-on-one game using deep reinforcement learning, not general soccer competence in every environment.
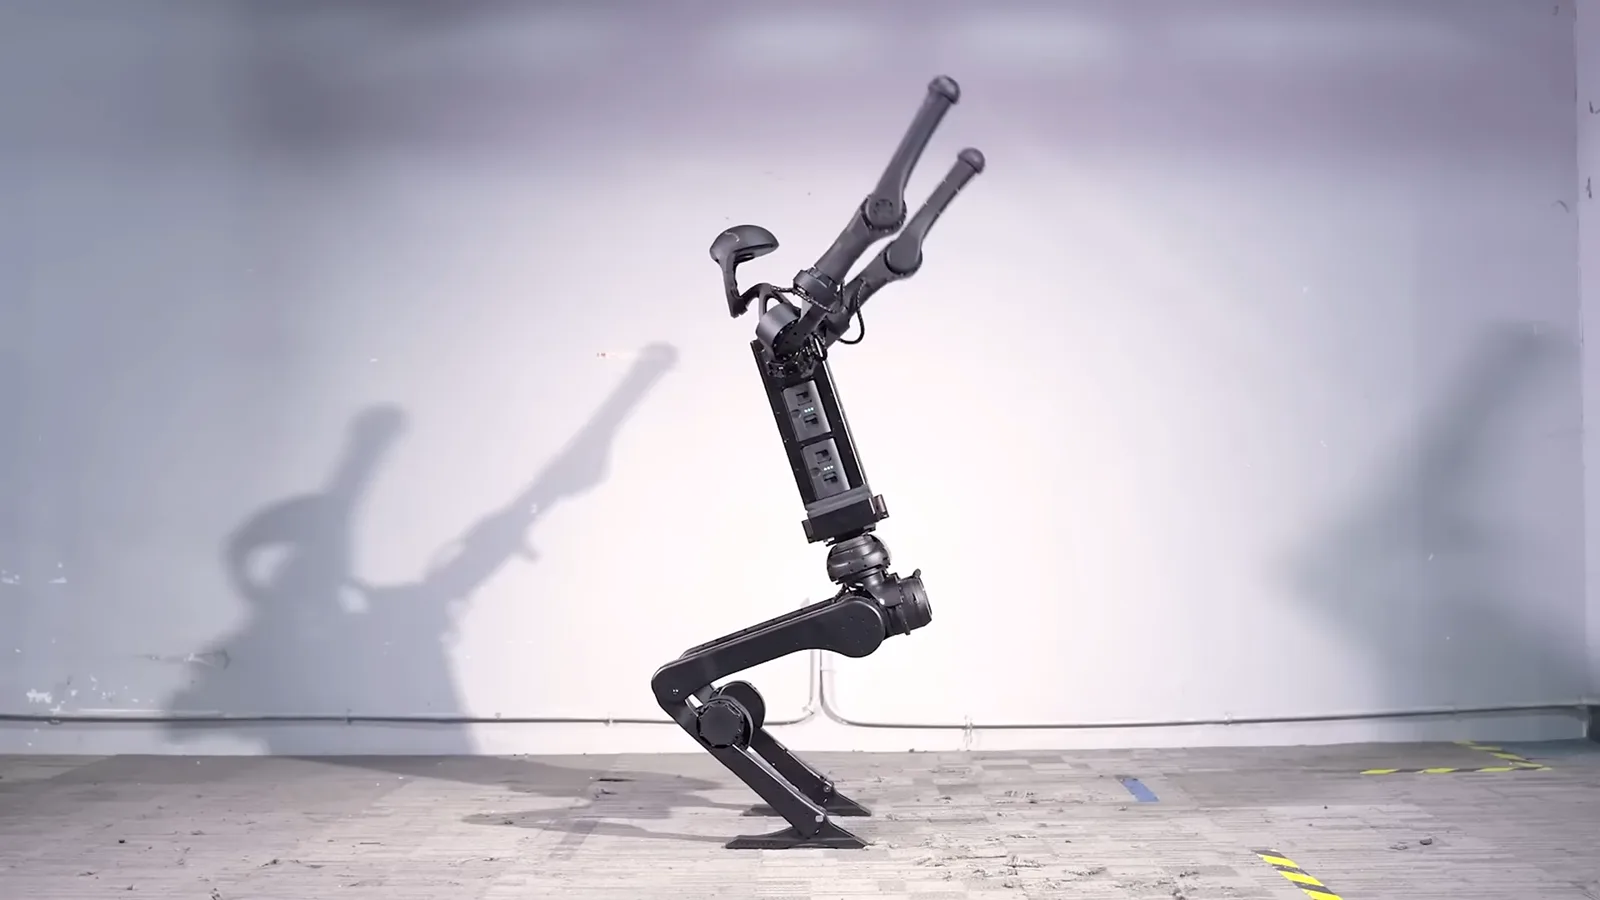
I compare a Booster Robotics demonstration of a robot standing from a lying position with the striking rise shown by Boston Dynamics' electric Atlas. The movements look similar to me, although the examples do not establish that the systems have identical hardware or capabilities.
Sponsor and more robot clips
A sponsored Bright Data segment precedes Unitree and research demonstrations. Berman then shows Ringbot and Sanctuary AI.
This segment is sponsored by Bright Data. I describe its data-collection and web-scraping services and say its marketplace and custom datasets can save time compared with building a collection stack yourself. Those are the sponsor's product claims, not independently verified comparisons.
Unitree has also released a group exercise video and footage of the H1 Evolution V4 performing a backflip. These clips show dynamic movements; they are selected demonstrations rather than a comprehensive test of safety or reliability.
I show highlights from research involving UC San Diego, Shanghai University and Fudan University. One researcher describes a robot cleaning up after his daughter at home. I find the example encouraging for household robots, but a demonstration does not establish that the system is ready for routine use in every household.
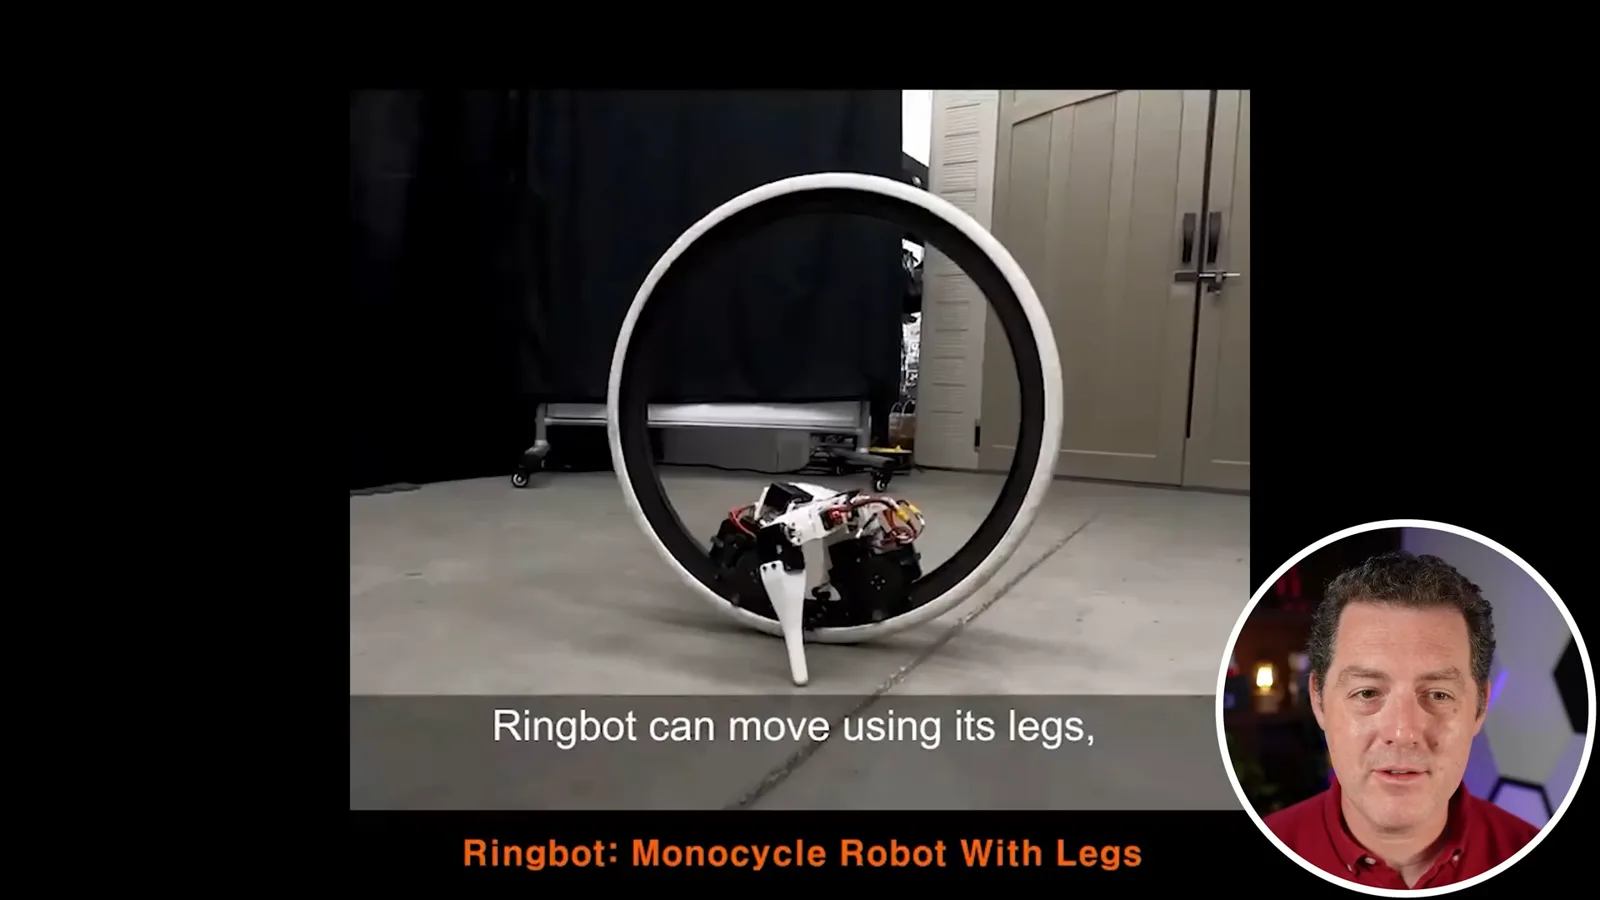
Another research video from Illinois shows Ringbot, a monocycle robot with a hybrid leg-and-wheel mechanism for navigating different terrain. Its rolling form reminds me of a robot from Star Wars.
Finally I show a newly announced Sanctuary AI robot. Across these demonstrations I see rapid progress and expect useful robots in the near future. That timing is my prediction; the videos do not show that the systems can safely and reliably perform all household chores today.
同じチャンネルの記事
 34:21EN
 Matthew Berman· 2026年10月27日Matthew Berman Examines Anthropic’s IPO Filing, AI Growth and GovernanceMatthew Berman, Sam Altman · Forward FutureThe presenter reviews the S-1’s financial metrics, compute strategy and voting structure while questioning the tension between rapid AI development and safety.
 0:26ENMatthew Berman· 2026年10月25日Sam Altman on Human Values and Problem-Solving in an AI WorldSam Altman · OpenAIIn a short interview excerpt, Altman considers the enjoyment of solving hard problems and the human role in interpreting results.
 0:36ENMatthew Berman· 2026年10月25日Kimi K3.1 and a Rubik’s Cube Solver DemonstrationMatthew Berman · Forward FutureMatthew Berman shows a scrambled virtual cube being solved and gives the Kimi K3.1 test a favorable assessment.
 0:21ENMatthew Berman· 2026年10月24日An AI-Generated Kimi Benchmark Chart Used Invented ScoresMatthew Berman · Forward FutureMatthew Berman asks for a graph of Kimi K3.1 Pro benchmarks, then discovers that the displayed figures are illustrative placeholders.
 25:50ENMatthew Berman· 2026年10月24日Kimi K3.1 Pro Tested: Strong 3D Demos, Uneven Results and Competitive PricingMatthew Berman · Forward FutureMatthew Berman tests the open-weight model on coding, 3D rendering and visual explanations, then compares benchmark results and prices.
 32:20ENMatthew Berman· 2026年10月23日Who Is Local AI For? The Costs, Trade-offs and a Hybrid FutureMatthew Berman · Forward FutureMatthew Berman weighs data control and independence against hardware cost, setup complexity and inference speed.