30 秒でわかる
In March 2024, Matthew Berman reviews Figure 01’s coffee demonstration and reports on the company’s funding, then surveys low-cost arms, learning from demonstration, robot football, teleoperation, a rolling drone and Amazon’s Digit test. He predicts rapid progress in robotics. The video title calls Figure an AGI robot, but these demonstrations do not establish general intelligence or prove that ChatGPT controlled the coffee task. The [UMI paper](https://arxiv.org/abs/2402.10329) describes purpose-built handheld grippers and a learning pipeline, rather than training from any ordinary video alone; Amazon described Digit as a test at its research facility.
- 1Figure’s financingBerman reports a $675 million funding round and names several prominent investors, as discussed in March 2024.
- 2A prepared coffee demoThe robot picks up a pod and operates a coffee machine; Berman notes the simple setup and an apparent correction.
- 3Low-cost armsBerman highlights a creator’s approximately $200 arm and later $600 multi-arm setup, both historical estimates for those specific prototypes.
- 4Learning from demonstrationUMI uses handheld grippers and a policy-learning pipeline, not arbitrary video alone.
- 5Digit was being testedAmazon described testing Agility Robotics’ Digit at its Seattle-area R&D site, not deployment of 750,000 humanoids.
ポイント
- Figure’s coffee clip shows a particular task in a prepared setting, including an apparent correction, not a general capability assessment.
- The video does not establish that ChatGPT controls the Figure coffee demonstration or that the robot has achieved AGI.
- Robot training methods differ: the examples include imitation learning, demonstrations, reinforcement learning and teleoperation.
- A low-cost arm estimate is not the price of a complete household robot.
- Amazon’s 2023 announcement described testing Digit at a research facility; its total robot count included other systems.
チャプターごとに整えた全文を読む
Figure 01 and the coffee task
Berman introduces Figure and its fundraising, then discusses a coffee-making clip and its prepared setup. The demo is not evidence of AGI.
Figure’s humanoid robot is the starting point for this March 2024 roundup. I discuss the company’s reported $675 million funding round and interest from major technology investors. Although the video title calls it an AGI robot, the clips shown do not establish artificial general intelligence or show that ChatGPT controls the coffee demonstration.
The Figure 01 clip shows a person asking for coffee and a robot operating a pod machine. The task is presented in a controlled setup with the machine, cup and pod positioned for the demonstration. A selected clip does not establish how frequently the system succeeds or how broadly it can handle unfamiliar kitchens.
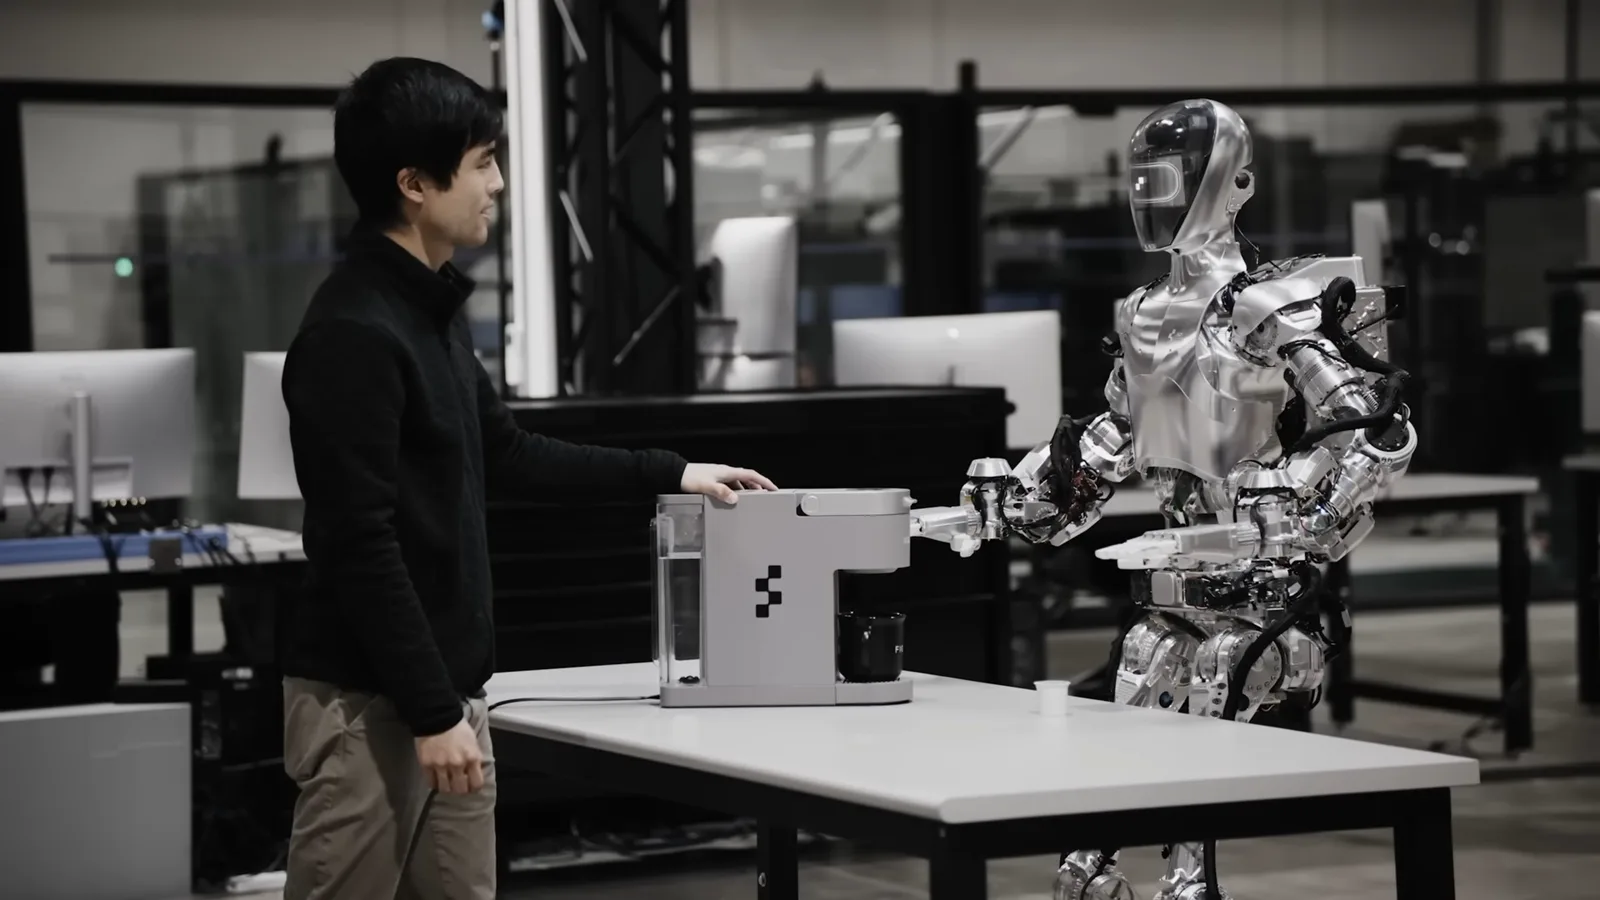
I acknowledge criticism that the setup simplifies the task, while finding it impressive that the robot picks up a capsule, inserts it, closes the machine and starts it. A separate excerpt appears to show a misplaced pod being corrected. The video alone does not verify all details of training, autonomy or reliability.
I expect a humanoid like Figure’s to be costly and contrast it with research platforms such as ALOHA. My roughly $30,000 recollection is a historical estimate for a particular research setup, not the price of a finished household product or an independently audited bill of materials.
Affordable arms and learned skills
He reviews low-cost robot arms, UMI and robot football. The examples use different methods and require task-specific data or training.
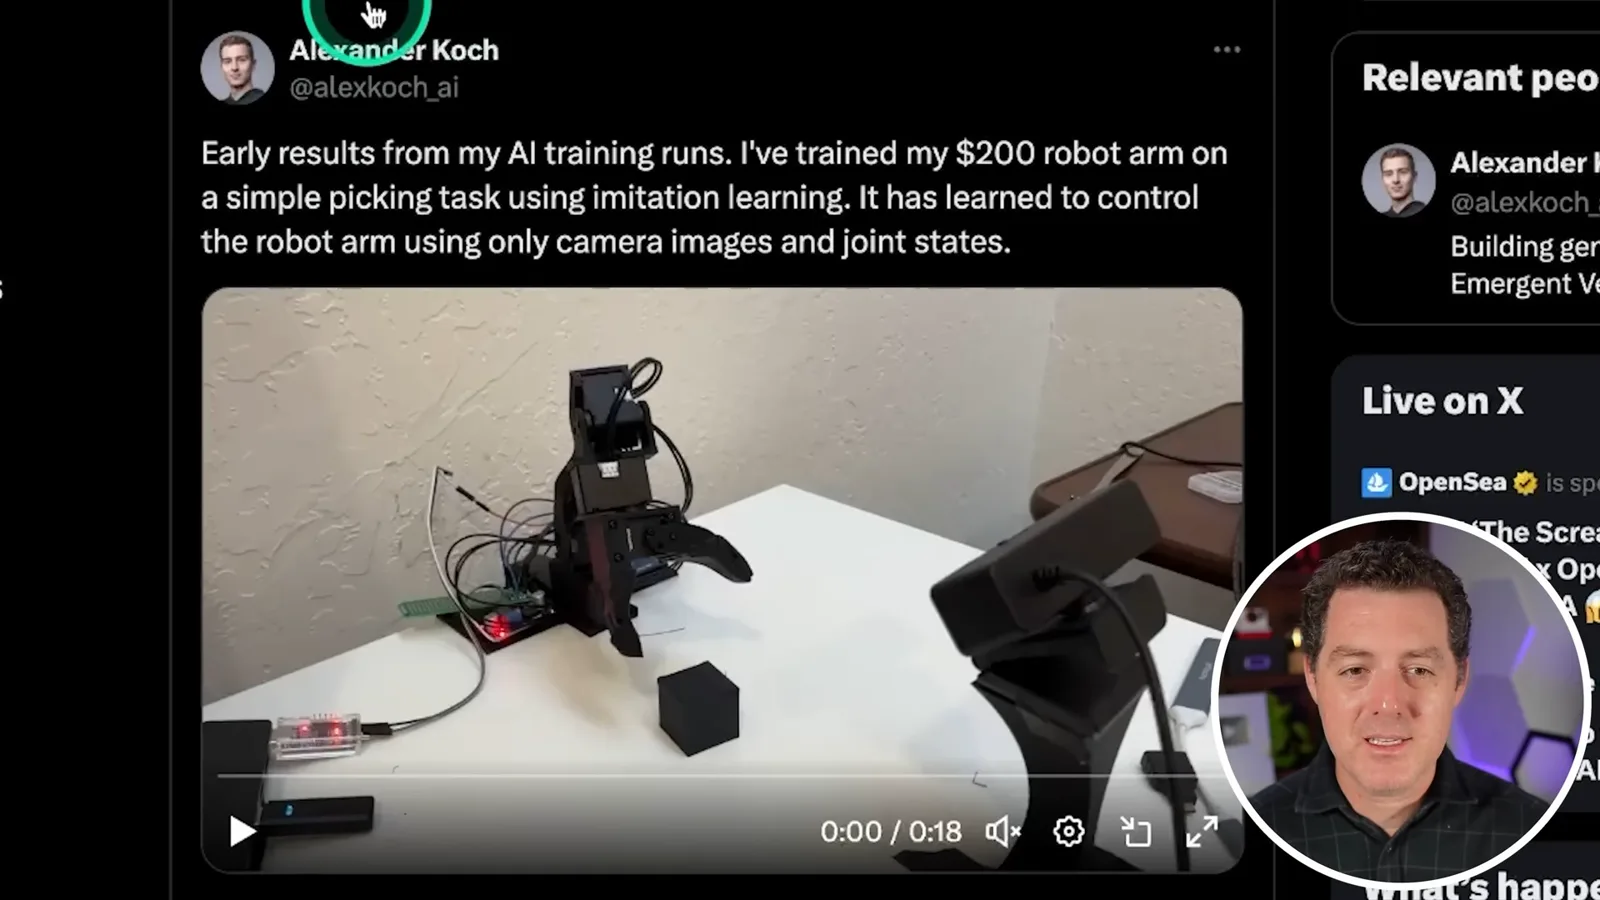
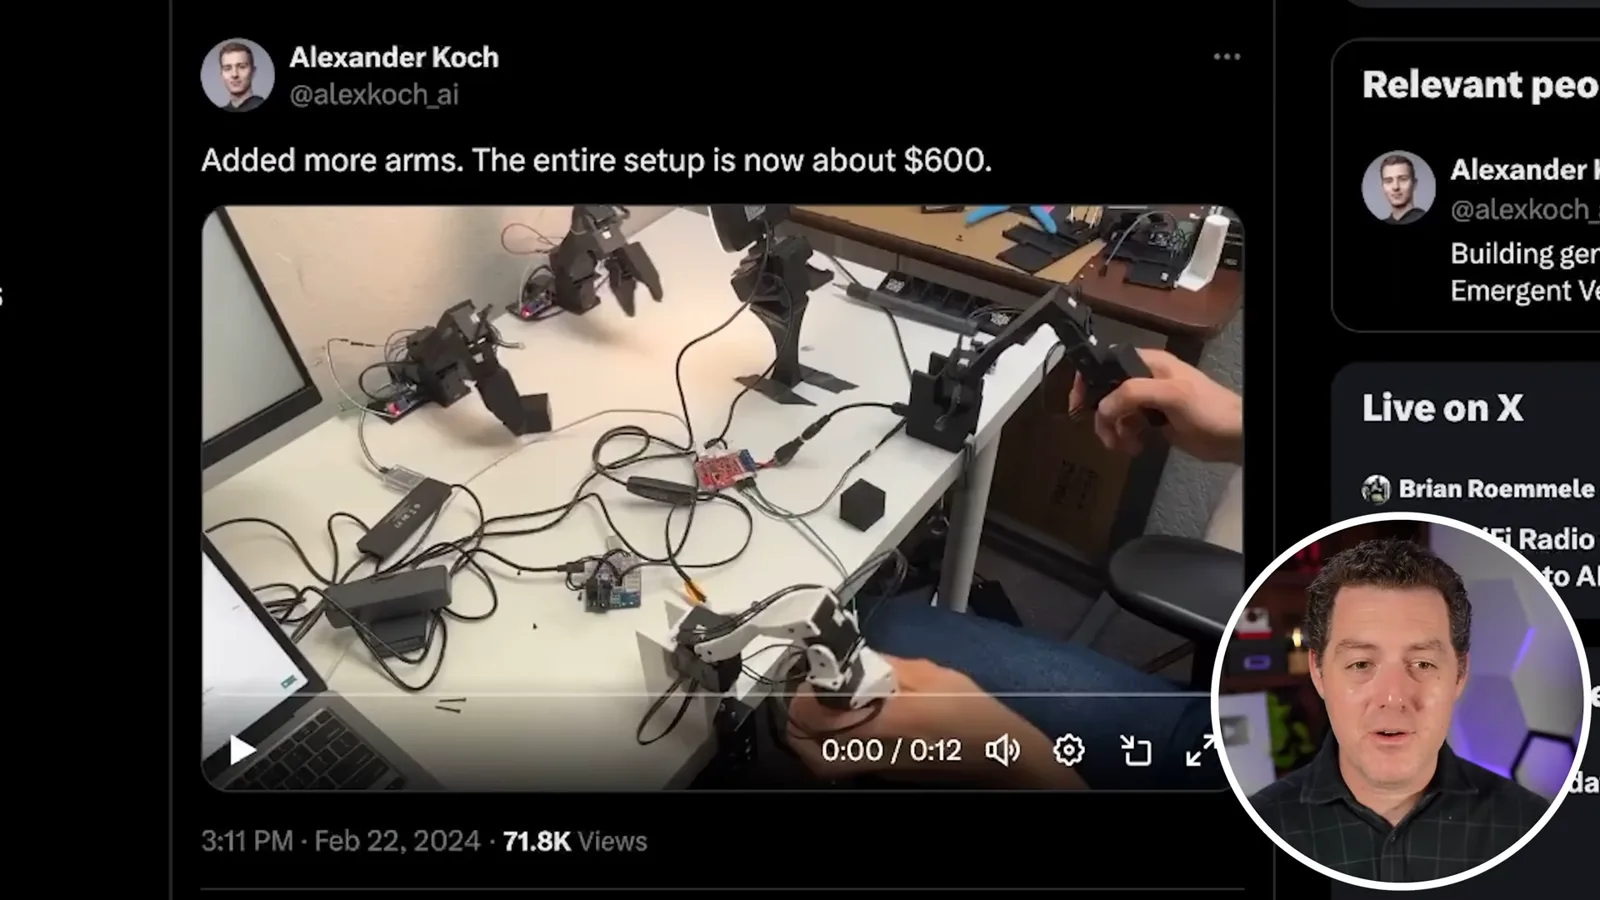
Alexander Koch shows a small arm he describes as costing about $200 and trained on a simple picking task using imitation learning, camera images and joint states. He later reports a multi-arm setup costing about $600 and demonstrates teleoperation. Those figures concern his prototype components, not a complete general-purpose robot.
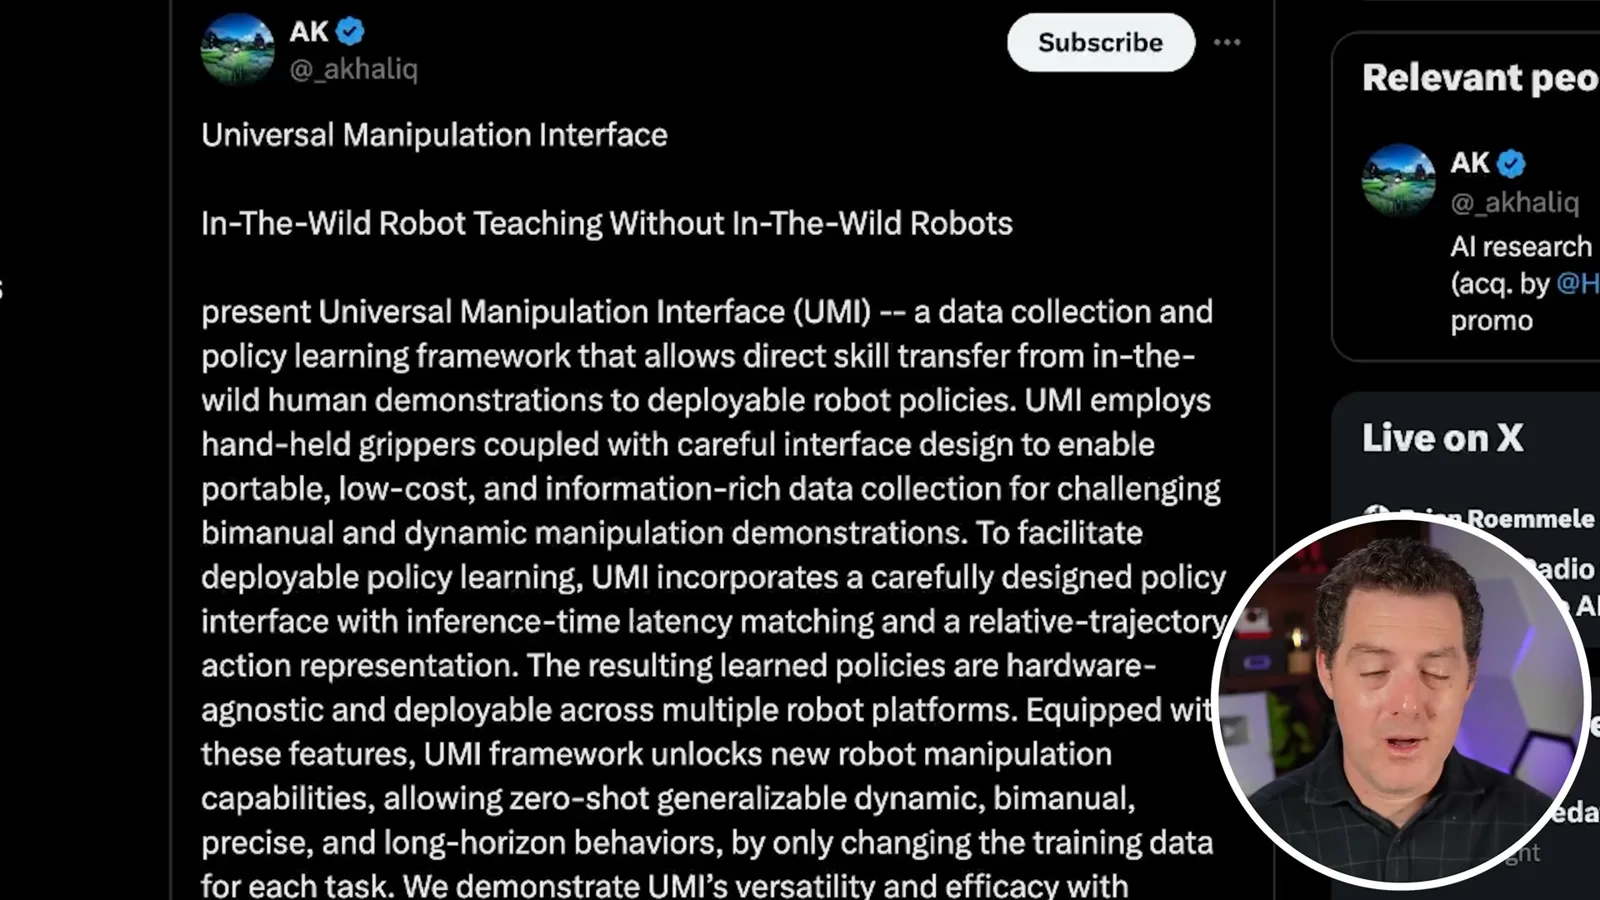
The Universal Manipulation Interface provides another way to collect human demonstrations. I describe it as teaching from video, but its researchers specify purpose-built handheld grippers with cameras and a data-processing and policy-learning pipeline. It is not simply a method for teaching any task from any ordinary video.
Another clip shows a small bipedal robot learning football skills through deep reinforcement learning. I emphasize reinforcement learning as a driver of progress, but the examples in this video use different approaches, including imitation learning and teleoperation; reinforcement learning alone does not explain them all.
Walking, teleoperation and warehouse testing
The remaining clips include Optimus, remote-controlled mining equipment, a rolling flying robot and Digit. Berman closes with an optimistic prediction for robotics.
A Tesla Optimus clip shows a robot walking in a lab, which I think looks increasingly natural. I then show remotely controlled mining equipment and discuss the possibility of operating machinery from a safer location. Teleoperation means a human is controlling the equipment; it is different from fully autonomous decision-making and does not eliminate every operational risk.
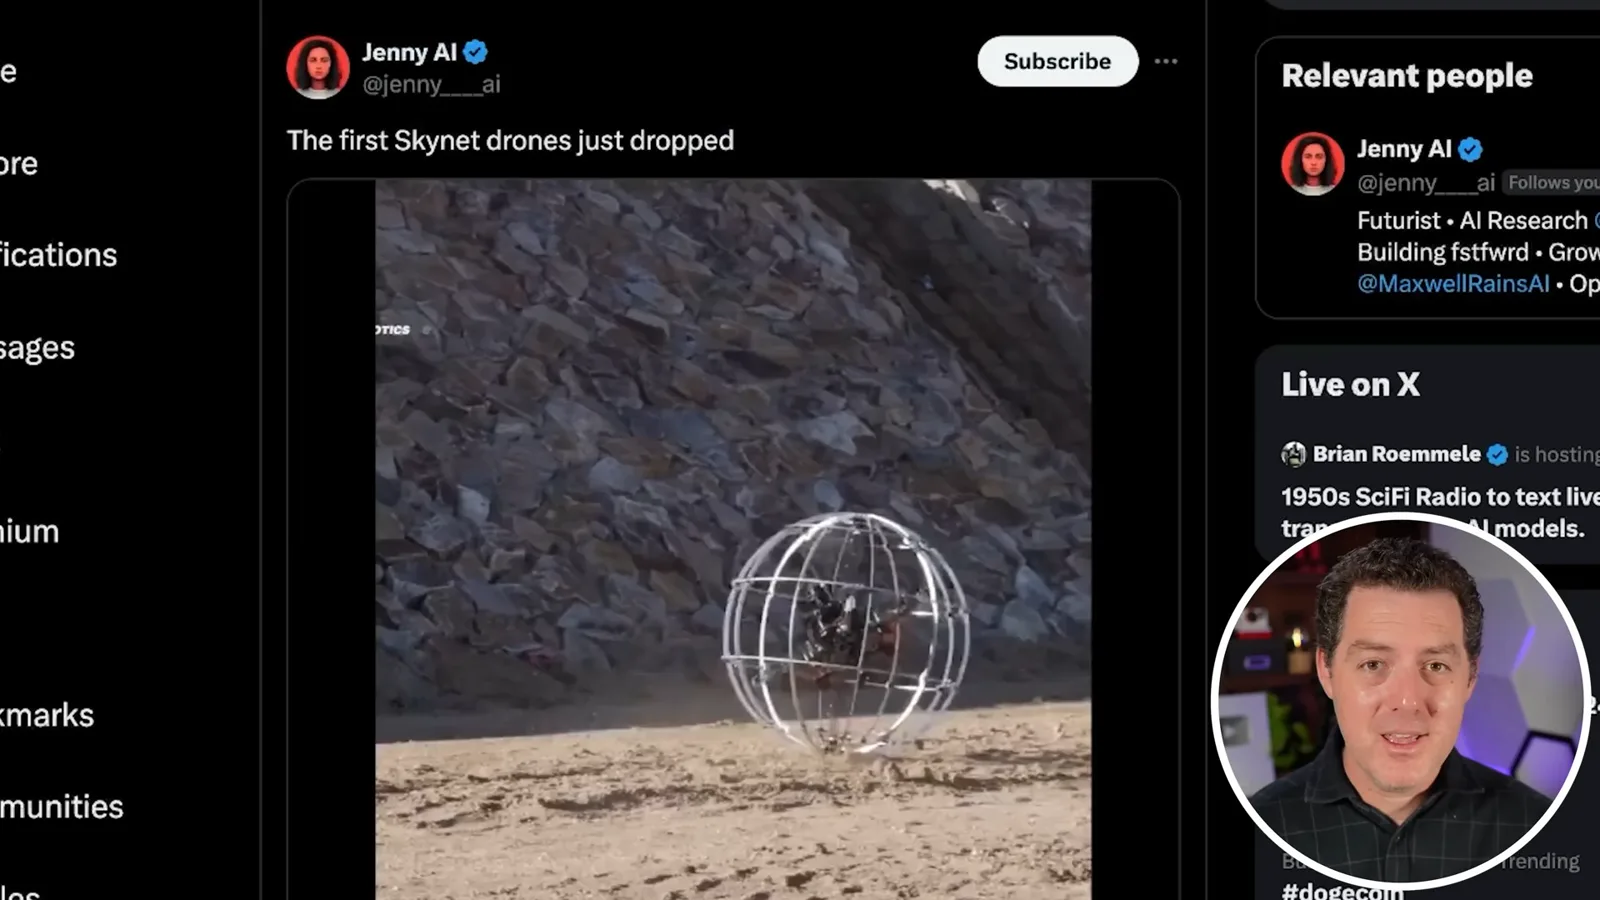
Another unusual robot encloses a drone in a spherical cage. The clip shows it rolling over terrain and then flying. The footage illustrates a form factor rather than establishing performance, autonomy or reliability across environments.
The final example concerns Agility Robotics’ Digit. Amazon said in October 2023 that it had begun testing Digit at its Seattle-area research and development site. Its figure of more than 750,000 robots referred to its broader robot fleet, not 750,000 Digit humanoids in warehouses. I close by predicting an active year for robotics; that is my outlook, not a demonstrated deployment forecast.
同じチャンネルの記事
 34:21EN
 Matthew Berman· 2026年10月27日Matthew Berman Examines Anthropic’s IPO Filing, AI Growth and GovernanceMatthew Berman, Sam Altman · Forward FutureThe presenter reviews the S-1’s financial metrics, compute strategy and voting structure while questioning the tension between rapid AI development and safety.
 0:26ENMatthew Berman· 2026年10月25日Sam Altman on Human Values and Problem-Solving in an AI WorldSam Altman · OpenAIIn a short interview excerpt, Altman considers the enjoyment of solving hard problems and the human role in interpreting results.
 0:36ENMatthew Berman· 2026年10月25日Kimi K3.1 and a Rubik’s Cube Solver DemonstrationMatthew Berman · Forward FutureMatthew Berman shows a scrambled virtual cube being solved and gives the Kimi K3.1 test a favorable assessment.
 0:21ENMatthew Berman· 2026年10月24日An AI-Generated Kimi Benchmark Chart Used Invented ScoresMatthew Berman · Forward FutureMatthew Berman asks for a graph of Kimi K3.1 Pro benchmarks, then discovers that the displayed figures are illustrative placeholders.
 25:50ENMatthew Berman· 2026年10月24日Kimi K3.1 Pro Tested: Strong 3D Demos, Uneven Results and Competitive PricingMatthew Berman · Forward FutureMatthew Berman tests the open-weight model on coding, 3D rendering and visual explanations, then compares benchmark results and prices.
 32:20ENMatthew Berman· 2026年10月23日Who Is Local AI For? The Costs, Trade-offs and a Hybrid FutureMatthew Berman · Forward FutureMatthew Berman weighs data control and independence against hardware cost, setup complexity and inference speed.