RESUMEN
En 30 segundos
Matthew Berman introduces a UC Berkeley bipedal robot and shows footage of it running on outdoor terrain. A support frame is visible in part of the footage. The short clip gives no measured speed or comprehensive assessment of autonomy.
- 1A bipedal research robotBerman introduces a two-legged robot from UC Berkeley.
- 2Outdoor footageThe video shows the robot moving outside; a support frame is visible in part of the demonstration.
- 3The sourceBerman identifies UC Berkeley as the source without giving a specific speed measurement.
Conclusiones
- The clip shows a two-legged robot associated with UC Berkeley.
- The footage includes outdoor running and a visible support frame.
- Berman calls the robot fast, but the clip supplies no measured speed or general reliability results.
TemasRobotics
TEXTO COMPLETO
Lee el texto editado por capítulos
01
An outdoor bipedal demo
Berman introduces a Berkeley robot and shows footage of it moving outdoors. The short clip does not give quantitative results.
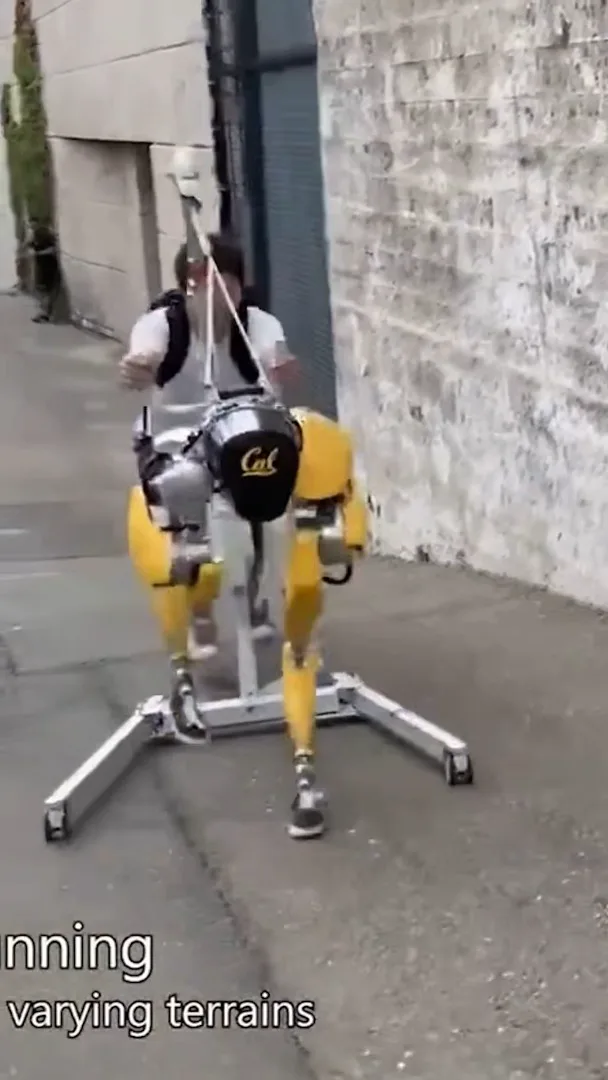
I call this the year of robots and show a two-legged robot from UC Berkeley running outdoors. I describe it as fast, but the clip provides no measured speed.
The footage shows the robot moving on outdoor terrain with a support frame visible in part of the sequence. It is a selected research demonstration, not a full assessment of independent operation or reliability.
Más de este canal
 34:21EN
 Matthew Berman· 27 oct 2026Matthew Berman Examines Anthropic’s IPO Filing, AI Growth and GovernanceMatthew Berman, Sam Altman · Forward FutureThe presenter reviews the S-1’s financial metrics, compute strategy and voting structure while questioning the tension between rapid AI development and safety.
 0:26ENMatthew Berman· 25 oct 2026Sam Altman on Human Values and Problem-Solving in an AI WorldSam Altman · OpenAIIn a short interview excerpt, Altman considers the enjoyment of solving hard problems and the human role in interpreting results.
 0:36ENMatthew Berman· 25 oct 2026Kimi K3.1 and a Rubik’s Cube Solver DemonstrationMatthew Berman · Forward FutureMatthew Berman shows a scrambled virtual cube being solved and gives the Kimi K3.1 test a favorable assessment.
 0:21ENMatthew Berman· 24 oct 2026An AI-Generated Kimi Benchmark Chart Used Invented ScoresMatthew Berman · Forward FutureMatthew Berman asks for a graph of Kimi K3.1 Pro benchmarks, then discovers that the displayed figures are illustrative placeholders.
 25:50ENMatthew Berman· 24 oct 2026Kimi K3.1 Pro Tested: Strong 3D Demos, Uneven Results and Competitive PricingMatthew Berman · Forward FutureMatthew Berman tests the open-weight model on coding, 3D rendering and visual explanations, then compares benchmark results and prices.
 32:20ENMatthew Berman· 23 oct 2026Who Is Local AI For? The Costs, Trade-offs and a Hybrid FutureMatthew Berman · Forward FutureMatthew Berman weighs data control and independence against hardware cost, setup complexity and inference speed.